AI Won’t Fix Robotics Software Problems. Physics and Math Will.
Nosa Edoimioya

Founder & CEO
Most robotics startups are focused on some aspect of building better software for robots to do X, where X is some application that really needs to be automated. The prevailing notion is that all the hardware challenges in robotics have been solved. All that’s left to do is write UI software that makes the robots more performant (faster, more dexterous, etc.). Easy enough, right? Plus, now we have AI. AI will solve all the challenges that we can’t solve with classical software.

Unfortunately, this view is incorrect. The design and mass manufacturing of robots has largely been solved, but that doesn’t mean we’ve solved all the hardware challenges. The software that controls the hardware is one of the major “hardware challenges” that still needs work. Let me explain:

To mass manufacture robots for many industries, some trade-offs need to be made. One of these trade-offs is using bare-bones (e.g., PID-based) control algorithms that enable repeatable positioning but not necessarily accurate positioning, meaning that the robot will go to the same (wrong) position 99.9% of the time. Another trade-off is that the control system can’t really account for objects it will interact with in the real world. Hence, the robot’s contact with these objects can impact both its repeatability and accuracy.

When software engineers encounter these problems, you may hear them say, “robots just aren’t accurate enough” or “robots just aren't strong enough” to do X application. But that’s not the whole story; there’s just more work to be done. Clearly, the robot manufacturers can’t write custom control software for each robot to meet each user’s accuracy/object specs. They depend on users (oftentimes through system integrators) to do that themselves while they focus on the important job of churning out general-purpose robots. However, developing control software to improve the robot’s performance requires a deep understanding of robot dynamics (i.e., physics) and control theory (i.e., abstract math), which are not typical learning outcomes in software engineering coursework.

So how do we tackle this mismatch? Can it be solved or are we cursed to never have high-performance robots running great software? To start, it’s helpful to recall how we got here.

The Software Boom and Bust

Back in 2013, when I got to Stanford, the landscape of software development was quite different. The tech industry had a shortage of computer programmers and my classmates who were majoring in Computer Science (CS) were in high demand for internships, almost guaranteed to get well-paying software development engineering (SDE) roles upon graduation. This trend was a direct result of the internet boom that began in the late 90s and continued through the early 2000s, driving a massive need for skilled programmers.

During this period, internet software companies like Google, Meta (formerly Facebook), Amazon, as well as several startups were in fierce competition to attract top talent. They offered extravagant compensation packages to lure the best software engineers and started the era of six-figure salaries for entry-level engineers. The demand for these skills was insatiable, fueled by both the rapid growth of the internet and competition to prevent talent from joining other companies or starting their own.

However, today we find ourselves in a much different place. We are now a decade past that explosive growth, and the dynamics of the tech industry have shifted. There is an increasing perception that we may have too many software engineers. Driven by the demand, software engineering education (both formal and informal) grew dramatically over the past decade. For example, CS consistently ranks as the most popular engineering major at top universities across the world. The same tech companies that were on the hiring sprees last decade are cutting back, and their focus has shifted to individuals with highly specialized skills, like knowledge of advanced machine learning algorithms.

There are two key features of internet software, in particular, that contributed to the decrease in demand:


  1. Scalability: Once the software was written, it could scale infinitely. The effort required to maintain and update the software was significantly less than the original work needed to build it. This scalability reduces the long-term demand for large numbers of software engineers. Additionally, the internet’s winner-take-all dynamics led to a few companies using their existing reach in one market to build bundled products that quickly grew their market share in other markets (think Google).

  2. Advancements in code automation: The recent rise of large language models (LLMs), and other code automation technologies before LLMs, revolutionized the way we approach software development. These products are great at generating and maintaining code, further reducing the need for a large workforce of engineers. Automation is compounded by the fact that there’s a lot of open-source internet code to use as data to train LLMs and other tools. In contrast, there isn’t nearly as much data for other types of software (e.g., embedded systems control software).


While the demand for software engineers is certainly not disappearing, the kinds of roles available are transforming. There is a growing need for SDEs to adapt and learn how to build for different kinds of systems outside internet software and this transformation is opening new opportunities, particularly in robotics.

The Transition to Robotics

As discussed above, transitioning from developing software for digital systems to creating software for hardware systems, like robots, is challenging for traditional software engineers. This difficulty largely stems from a lack of training in the fundamental principles of physics and mechanics, which are crucial for understanding and manipulating the physical world.

However, hope is not lost. We’ve seen remarkable early examples of software engineers partnering with experts in the sciences to build innovative real-world capabilities. A prime example of this collaborative success is the research on protein folding. By combining new software algorithms (like Transformers) with decades of biological research into the structure of proteins, researchers achieved groundbreaking results (see AlphaFold from Google DeepMind and structure-informed language models from Stanford). The same synergy between different domains of expertise is also paving the way for similar advancements in robotics (see Covariant and Dexterity)! The playbook seems to be: (1) a strong understanding of the underlying nature of the problem, rooted in scientific fundamentals, then (2) the addition of elegant software to transform scientific insights into efficient code. Unfortunately, software is not good enough on its own and AI is not good enough on its own. (Heck, physics isn’t good enough on its own.)

Recently, I've noticed a growing trend of early-career SDEs expressing an interest in pivoting to robotics. This is good news. They’re becoming aware of the saturation of talent in the digital software market and are interested in the relatively untapped potential of robotics. However, at the risk of repeating myself, I would caution these engineers against the belief that software or AI alone will solve robotic automation problems. Instead, I would recommend a study of fundamental robot mechanics (you can start with Robot Dynamics and Control by Mark Spong) and finding a mechanics or controls expert to work with.

How Reforge Robotics Fits In

At Reforge Robotics, we are well-positioned to benefit from this influx of CS talent. Our team has a strong background in physics and control engineering, which complements the skills of strong software engineers to build robust robot applications.

We intend to drive advancements in robotics and automation in the manufacturing industry. Through the combination of physics-based robot control and user-centered software development, we can handle complex physical environments in manufacturing and meet the needs of our customers with software that is 10x easier to use than traditional machines.

As the value of our products for manufacturers becomes increasingly evident, we anticipate a continued surge of interest from software developers eager to build applications for manufacturing robots on our underlying architecture. We plan to build APIs for other developers to use our robot models and controllers to build software for more applications and use-cases. This model reminds me of how NVIDIA showcased the practical benefits of accelerated computing via their GPUs by enhancing computer graphics applications and subsequently built CUDA, a platform that enabled developers to write accelerated computing code. Today, many AI platforms run on NVIDIA’s chips using CUDA software. We anticipate a similar trajectory for Reforge Robotics.

Today, we are in the infancy of automation and the transition to automating physical systems presents both challenges and opportunities. The future of robotics demands a convergence of computer science and the physical sciences. This interdisciplinary approach will lead to scalable physical interactions between robots and their surroundings, particularly in the manufacturing context. By building a collaborative ecosystem where the best software engineers and physical engineers/scientists can work together, we can overcome the challenges and leverage the opportunities.

We intend to build the next generation of manufacturing systems by combining: (1) the hard-won software engineering efficiencies developed over the past decade, and (2) a modern (and historical) understanding of the physical sciences, driven by advancements in fundamental research. Reforge Robotics is committed to being a pioneer in this new era. Our strategy will not only drive advancements in manufacturing automation but also create a framework for many other industries to adopt robotic automation.

Nosa Edoimioya

Founder & CEO

Share post
Written by

Nosa Edoimioya, Founder & CEO

Published on

Continue Reading

Industrial robot arm probing a compact calibration fixture, with a laser tracker in the background

10/2/26

$35 Calibration vs. $50k Laser Tracker

By Iago Alves Pereira

The economics of robot calibration are changing. Here's what that means.

For most of the history of industrial robotics, there's been exactly one way to make a robot more accurate: hire a metrology specialist, rent or buy a laser tracker, shut down the cell, and spend hours — sometimes days — running a calibration procedure that most teams can't do in-house.

Laser trackers work. They measure position with sub-micrometer precision, and for applications that need that level of accuracy — aerospace machining, precision medical device assembly, high-value metrology — the investment makes sense. The parts are worth enough to justify $50,000 to $150,000 in equipment, plus the engineering time to operate it.

But here's what we've learned from talking to dozens of robotics teams: most of them don't need sub-micrometer accuracy. They need their robot to actually go where the controller says it should go. And for that problem, the laser tracker has always been overkill — not because the technology is wrong, but because the cost structure makes it inaccessible to the teams that need calibration the most.

The teams that live with the error

The robotics teams we talk to — cobot OEMs, system integrators, precision manufacturing operations — are building systems where accuracy matters but the unit economics don't support traditional metrology.

A startup building a cobot for lab automation can't justify a $50,000 laser tracker for every unit they ship. An integrator deploying welding cells for a contract manufacturer isn't going to bring in a metrology specialist every time they commission a new robot. A warehouse automation company running hundreds of arms across multiple sites can't shut down production for a full-day calibration on each machine.

So they live with the error. They run slower to hold tolerance. They spend days on touch-up programming to teach each robot where things actually are versus where the kinematic model says they should be. They accept that programs aren't portable between nominally identical cells because each robot has a slightly different error signature.

These aren't teams that don't care about accuracy. They're teams that can't afford the cure.

What changed

The fundamental insight behind our approach to kinematic calibration is that you don't need external metrology equipment to identify a robot's real geometric parameters. You need the robot's own sensors and a known reference.

Our calibration process uses a commodity hardware fixture — a precision calibration target that can be built from off-the-shelf components for under $35 and assembled in under five minutes. The robot touches or approaches the target in a structured sequence of configurations, and from the joint encoder data at each configuration, we identify the actual kinematic parameters of the machine. Link lengths, joint axis orientations, offsets, frame alignments — the real values, not the nominal ones from the manufacturer's datasheet.

The calibration takes approximately 10 minutes. No laser tracker. No metrology specialist. No production shutdown beyond the time it takes to run the routine.

The results

We've validated this approach across multiple robot platforms. The measured improvement: positional accuracy improves from roughly 0.6 to 1.0mm down to 0.18 to 0.21mm. That's a 3x to 5x improvement in absolute accuracy.

To put that in context: a robot with 1mm of positional error needs touch-up programming for almost any precision task. A robot with 0.2mm of positional error can run from offline-generated paths. That's the difference between a cell that takes a week to commission and one that takes a day. Between a program that needs to be re-taught on every robot and one that deploys to the fleet.

The accuracy we achieve isn't laser-tracker-grade. We're not claiming sub-0.1mm performance. For applications that genuinely need that — and some do — traditional metrology is still the right tool. But for the vast majority of robotic applications, getting from 1mm to 0.2mm is the step change that matters. It's the threshold where calibration goes from "nice to have" to "the robot actually works."

The cost comparison

The math is straightforward.

Traditional calibration:

  • Laser tracker: $50,000 to $150,000 (purchase or rental)

  • Metrology specialist: typically contracted, hourly or daily rate

  • Production downtime: hours to a full day per robot

  • Recalibration frequency: rarely repeated because of cost, even when accuracy drifts

Software-based calibration:

  • Calibration fixture: under $35 in commodity parts, assembles in under 5 minutes

  • Specialist required: none — the calibration routine runs through the SDK

  • Production downtime: approximately 10 minutes

  • Recalibration frequency: can be repeated after every collision, tool change, maintenance window, or on a regular schedule

The per-robot cost drops by orders of magnitude. But the more important shift is what becomes economically viable when calibration is cheap.

What changes when calibration is affordable

When calibration costs $50,000, you calibrate once and hope the robot doesn't drift. When it costs 10 minutes of downtime, the whole relationship between accuracy and operations changes.

Routine recalibration. Robots drift. Gearbox backlash increases. Bearings develop play. Thermal changes shift the geometry. A collision throws everything off. With affordable calibration, you can recalibrate on a schedule — weekly, monthly, after every maintenance window — the same way you'd change oil in a car. Not because the robot has catastrophically failed, but because maintaining accuracy is now cheaper than living with drift.

Per-unit calibration at scale. If you're an OEM shipping hundreds of robots, per-unit calibration at the end of the manufacturing line becomes a realistic quality step. Every robot ships with a calibrated kinematic model that reflects its actual geometry, not the nominal geometry from the CAD model. The customer receives a robot that goes where it's told from day one.

Fleet-wide accuracy. For operations running multiple robots — across a facility, across sites — affordable calibration means programs become portable. Calibrate each robot to the same standard, and the program that works on one machine works on all of them. The per-robot variation that currently forces per-robot commissioning gets resolved at the calibration step, not the programming step.

Recovery after incidents. Collisions happen. Currently, a collision that changes the robot's geometry means calling in a specialist or living with degraded accuracy until the next scheduled maintenance. With a 10-minute recalibration, you recover immediately. The robot is back to spec before the next shift.

The laser tracker isn't going away

We're not arguing that laser trackers are obsolete. For applications that need sub-0.1mm accuracy — and they exist — precision metrology equipment remains the right tool. For calibrating large-scale structures, multi-robot cells with tight relative positioning requirements, or applications where traceability to metrology standards is a contractual requirement, laser trackers earn their cost.

What we are arguing is that the vast majority of robots running in production today don't need laser-tracker-grade calibration. They need to close the gap between where the controller thinks they are and where they actually are. And for that problem, the economics have fundamentally changed.

The question is no longer "can we afford to calibrate?" It's whether you can afford not to — when the alternative is 10 minutes and $35.

Reforge Robotics builds motion control software that makes robot calibration fast, affordable, and repeatable.

9/25/26

Why We Use Physics, Not AI, to Improve Robot Performance

By Nosa Edoimioya

Our model is deterministic, not probabilistic. That's a deliberate choice.

One of the first questions we get in technical conversations is: "Is this a machine learning model?"

It's a reasonable assumption. In 2026, if someone tells you their software improves robot performance using a calibrated model, the default mental model is a neural network trained on data. The entire industry has been conditioned to assume that "model" means "learned from data in a way that's hard to explain."

Our model is not that. It's a physics-based, deterministic simulation of the robot. And the distinction matters more than you might think.

What the model actually is

When we calibrate a robot, we're building a mathematical replica of how that specific machine responds to commanded inputs. Not a statistical approximation. Not a learned mapping from inputs to outputs. A physics model.

A frequency response plot from a real calibration. The peaks show where the robot's structure amplifies motion — exactly what the physics model captures and compensates for.

The model captures the robot's frequency response characteristics — how the physical system amplifies, attenuates, and delays motion commands across the frequency spectrum. Every robot arm is a mechanical system with mass, stiffness, damping, friction, and compliance at every joint and link. Those physical properties determine how the structure responds when you command a motion. Our calibration process measures those responses and builds a model that reproduces them.

Given a tool path, the model predicts exactly how the robot will behave — where it will overshoot, where it will vibrate, where it will lag. Then we use optimization to modify the input command so that the robot's actual behavior matches the intended path. The controller doesn't learn a general mapping from experience. It predicts the specific physical response and compensates for it.

The output is deterministic. Same input, same model, same output. Every time.

Why not machine learning

We considered it. In the early days, we explored learned models. The appeal is obvious — let the data speak, don't impose assumptions about the physics, let a neural network figure out the relationship between commanded trajectories and actual behavior.

Here's what we found.

ML models learn correlations from training data. Physics models encode the system that generates the data.

Learned models are robust to what they've seen. A neural network trained on a set of trajectories performs well on similar trajectories. Move outside the training distribution — a new speed profile, a new payload, a different region of the workspace — and the predictions degrade in ways that are difficult to predict in advance. You don't know the boundary of what the model knows until you cross it.

Physics models generalize by construction. If the model correctly captures the mass, stiffness, and damping of the system, it predicts behavior for any trajectory, any speed, any payload within the system's physical limits. The model doesn't need to have seen a specific motion before. It understands the system that produces the motion.

Determinism is not optional for control. When you're modifying the commands that a robot's actuators receive, you need to know exactly what the controller will do. Not approximately. Not with a confidence interval. Exactly.

A probabilistic model has an inherent uncertainty band. For planning, for analysis, for decision support, that uncertainty band is manageable. For real-time control — where the output of the model directly determines the forces applied to a mechanical system — uncertainty means risk. A controller that occasionally produces unexpected outputs is a controller that occasionally moves the robot in ways you didn't intend.

We can't ship that. Our customers operate in environments where unexpected robot behavior has real consequences.

Explainability matters for adoption. When an engineer evaluates our software, they want to understand what it does. Not conceptually — specifically. What does the model capture? Why did it produce this output? If the result is wrong, where is the error?

A physics model answers those questions directly. The model has parameters — masses, stiffnesses, damping ratios, friction coefficients — that correspond to physical properties of the real machine. If the model's prediction doesn't match reality, you can identify which parameter is wrong and why. The debugging process follows the same engineering reasoning that roboticists already use.

A learned model doesn't offer that. The weights of a neural network don't correspond to physical quantities. When a learned model fails, the diagnostic is "retrain with more data" or "the input was outside the training distribution." That's not a diagnosis. It's a restart.

What we gain from physics

The physics-based approach has constraints. It requires a structured calibration process. It requires that we know enough about the physical system to write down the relevant equations. It doesn't handle phenomena we haven't modeled.

But it gives us three things that matter enormously in production:

Predictable behavior at boundaries. Our customers push robots to the edges of their performance envelopes — higher speeds, heavier payloads, longer duty cycles. Physics models degrade gracefully at boundaries because the equations remain valid even as the system approaches its limits. The predictions become less accurate as unmolded effects grow, but they don't suddenly produce nonsensical outputs. They fail in ways that make physical sense.

Per-robot specificity without per-robot training data sets. Every robot we calibrate gets a model tuned to its specific physical parameters. But the calibration process is structured and efficient — typically 5 to 10 minutes for kinematic calibration, 5 to 10 minutes for the feed-forward controller. We don't need hours of trajectory data covering the robot's full workspace. We need a targeted measurement of the system's physical properties.

Transferability across robots of the same SKU. This is a question we get frequently: if you calibrate one robot, does it work on identical robots? With a physics model, the answer is nuanced but useful. Robots of the same SKU share the same basic structure, so a model calibrated on one unit captures roughly 90% of the performance on siblings. The last 10% is per-unit variation — manufacturing tolerances, installation differences, wear. Per-robot calibration closes that gap, but even without it, the physics model provides a strong starting point because it's modeling the right system.

A learned model doesn't transfer as cleanly, because the learned weights encode not just the physics but also the specific noise and artifacts of the training data. A model trained on unit A doesn't generalize to unit B the way a physics model parameterized from unit A does.

The AI distinction that matters

We use the word "model" deliberately. In our context, it means a mathematical representation of a physical system — the same way an aerospace engineer builds a flight dynamics model or a structural engineer builds a finite element model. It predicts behavior from first principles and physical measurements.

We don't have anything against machine learning. We use data-driven techniques in parts of our pipeline where they're appropriate — certain aspects of system identification benefit from optimization methods that could loosely be called "learning." But the core model that drives the controller is physics. It's deterministic. It's explainable. And it produces the same output every time you give it the same input.

When a customer asks "is this AI?", the honest answer is no. And we think that's a better answer for what we're trying to do.

The robots we're improving operate in production environments where predictability, repeatability, and explainability aren't nice-to-have features. They're requirements. A physics model meets those requirements by construction. That's why we chose this path, and it's why we're staying on it.

Same input, same model, same output. Every time.

Reforge Robotics builds open-source motion control software that helps robots move faster, track more accurately, and behave more predictably.

9/13/26

The Backlash Problem in Robotic Machining and What Software Can Do About It

By Nosa Edoimioya

Gear backlash is one of the largest sources of dimensional error in robotic milling. Here's what it does to your parts and how software-based compensation addresses it.

Robotic milling is gaining ground as an alternative to 5-axis CNC for large, complex, and low-volume parts. A KUKA KR 500, Fanuc M-900, or ABB IRB 6700 costs a fraction of a comparable gantry mill, offers a larger work envelope, and can be repurposed across part families. But accuracy remains the constraint that keeps many machining operations from making the switch.

One of the biggest contributors to that accuracy gap is backlash — and it shows up exactly where milling demands the most from the robot: at direction changes.

What is backlash?

Backlash is the small amount of free movement between mating mechanical components — particularly gears — when the direction of motion reverses. Every gear-driven joint in a robot arm has some backlash. It's a function of manufacturing tolerances, gear geometry, wear, and assembly.

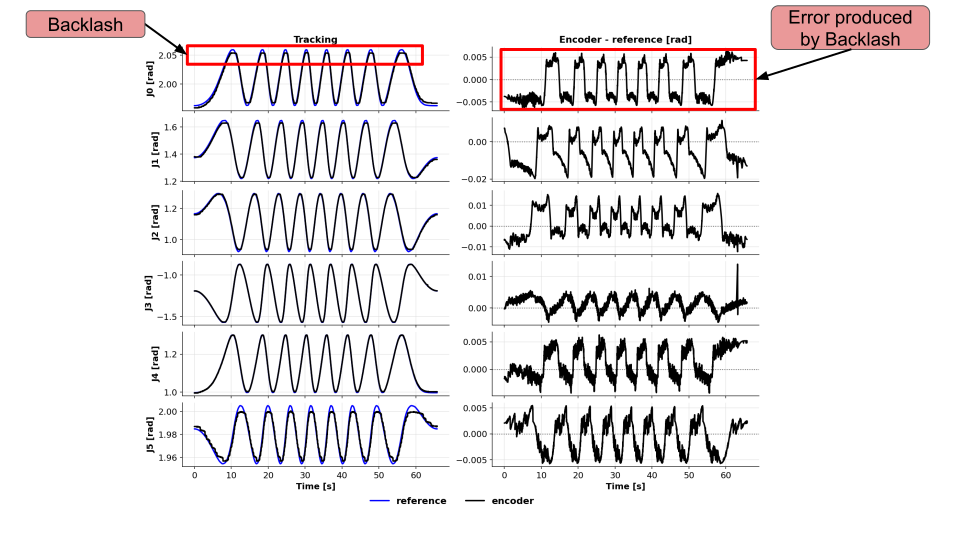
The mechanism is straightforward. When a motor drives a joint in one direction, the gear teeth are in contact on one side. When the motor reverses, it must cross the backlash gap — the clearance between teeth — before the gear teeth engage on the opposite side and the joint begins moving again. During that crossing, the motor moves but the joint does not. The encoder reads a position change that hasn't happened at the link.

For a typical industrial robot, backlash per joint ranges from 0.05° to 0.3°. That sounds small, but it compounds. A 0.1° backlash error at a single joint propagates through the kinematic chain. At the end of a 2-meter arm, it becomes 3 mm or more of TCP positioning error.

Joint encoder readings and tracking error during repeated direction reversals

Encoder readings and tracking error during repeated reversals in the Reforge validation test.

Why milling exposes backlash more than other applications

Pick-and-place, welding, and palletizing applications often mask backlash because the robot moves in long, sweeping arcs with few reversals. The joints move predominantly in one direction for each segment of the path.

Milling is different. A robot following a contour — profiling a turbine blade root, machining an aircraft skin panel, or cutting a composite layup — reverses joint directions constantly. Every concave-to-convex transition, every pocket corner, every change in contour curvature forces one or more joints through a reversal. Each reversal triggers the backlash gap.

The result is visible on the part:

  • Witness marks at direction changes — small steps or ridges where the tool path shifts by the backlash error as joints reverse

  • Dimensional errors on contoured surfaces — the TCP tracks inside or outside the programmed path depending on the direction of approach

  • Surface finish degradation at corners and transitions — the tool dwells or skips as joints cross their backlash gaps, producing chatter marks or uneven material removal

  • Non-repeatable errors — because backlash depends on the direction of the last motion, the same programmed path can produce different results depending on how the robot arrived at each point

These errors are distinct from the robot's static accuracy specification. A robot with ±0.05 mm repeatability can still produce 1-3 mm of path error during contour milling if backlash is uncompensated.

How shops deal with backlash today

The current approaches all involve working around the problem rather than solving it:

Approach

What it does

Trade-off

Reduce feed rate

Slows the robot to minimize dynamic effects

Cycle time increases 2-5x; backlash gap still exists, just crossed more slowly

Harmonic drives

Reduces the physical clearance between gear teeth

Higher cost per joint; Add compliance on the robot which limits payload

CAM path compensation

Creates a tool path that avoids joint reversals instead of compensating for the backlash

Do not work for the for tool paths where backlash can not be avoided

Finishing passes with manual correction

Operator measures and corrects after the robot pass

Defeats the purpose of automation; adds labor cost per part

Buy a more expensive robot

Higher-end platforms with tighter mechanical tolerances

KUKA or Fanuc precision series costs 2-4x more; still has backlash, just less of it

None of these approaches address the root cause: the controller doesn't know the backlash exists and can't compensate for it in real time.

How software-based backlash compensation works

Software-based compensation operates between the trajectory planner and the robot's native servo controller. It tracks the direction of motion at each joint and applies a correction when a reversal is detected.

The process has two parts:

Calibration. The system drives each joint through a structured sequence of reversals and measures the actual deadband — the angular gap where the motor moves but the link does not. This is done once per robot and captures the specific backlash characteristics of that arm, including any asymmetry between joints and any configuration-dependent variation.

Real-time compensation. During operation, the software monitors the commanded trajectory for direction reversals at each joint. When a reversal is detected, it injects a correction equal to the identified deadband, so the motor crosses the backlash gap before the joint is expected to begin moving in the new direction. The joint starts its new motion already in contact — eliminating the lag.

This layer works alongside existing accuracy improvements. Kinematic calibration corrects the robot's geometric model. Dynamic joint tracking compensates for compliance and lag. Backlash compensation handles the direction-reversal error that neither of those can address. Together, they reduce the total path error to a level that starts approaching what many milling operations require.

Measured results

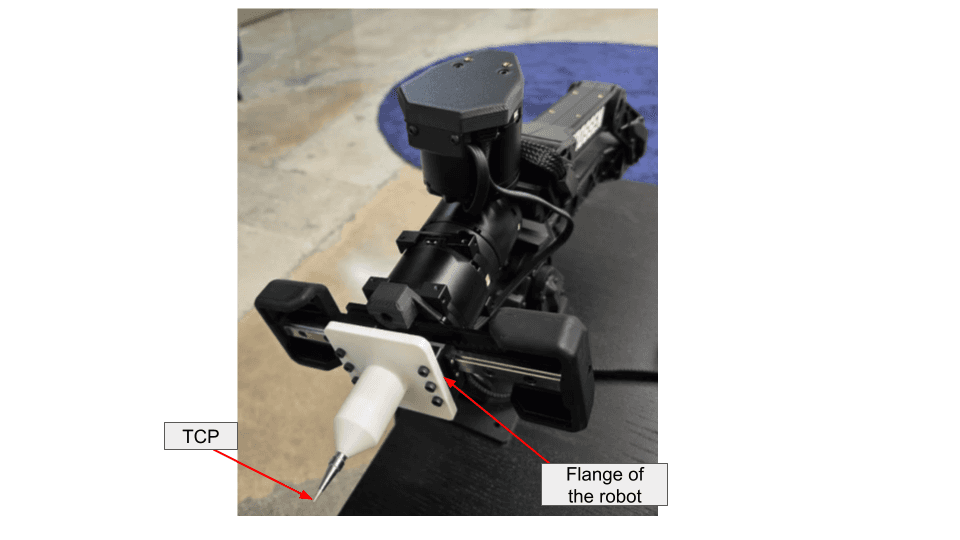
We validated backlash compensation on a trajectory specifically designed to force repeated joint reversals — the kind of multi-axis coordinated motion that robotic milling demands. The robot was commanded to track a circle with the flange center while holding the TCP fixed in Cartesian space, requiring all six joints to reverse direction continuously.

The validation setup: the metal tip marks the TCP, and the labeled flange follows the commanded circle.

Validation test setup with the metal-tip TCP and robot flange labeled

Metric

Without compensation

With compensation

Improvement

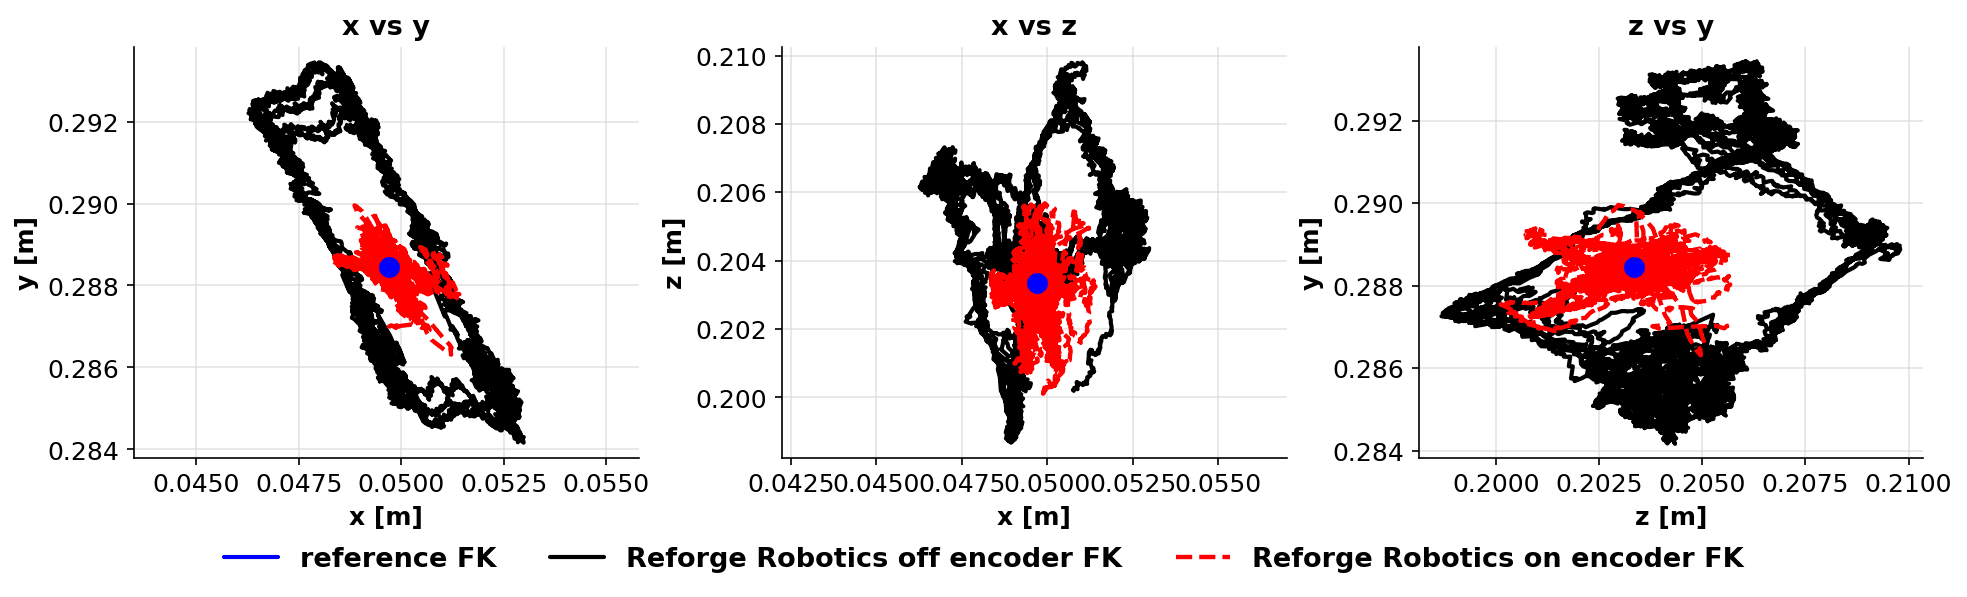
3-D TCP RMS tracking error

4.131 mm

0.878 mm

4.70×

All-joint RMS tracking error

0.593°

0.088°

6.75×

Estimated TCP position with Reforge software off and Joint Tracker plus Backlash Compensation on

Estimated TCP position in the validation test. Black is software off, red is Joint Tracker plus Backlash Compensation on, and blue marks the fixed reference. These measurements evaluate the combined software effect, not backlash compensation alone.

The per-joint results show that the compensation is effective across all joints, not just the ones with the largest backlash:

Joint

Without compensation

With compensation

Improvement

J0

0.330°

0.076°

4.37×

J1

0.948°

0.117°

8.11×

J2

0.927°

0.108°

8.59×

J3

0.320°

0.071°

4.52×

J4

0.319°

0.051°

6.26×

J5

0.204°

0.088°

2.32×

A 4.70× reduction in TCP tracking error during direction reversals changes what robotic milling can achieve. For a cell that was producing ±2 mm contour error, that drops to under ±0.5 mm — moving from rough machining territory into semi-finishing range without changing the robot, the spindle, or the CAM program.

What this means for your milling operation

Backlash compensation doesn't turn a robot arm into a 5-axis CNC. The robot still has structural compliance, thermal drift, and dynamic limitations that a purpose-built machine tool doesn't. But it removes one of the largest discrete error sources in robotic machining — and it does it through software, without mechanical modification.

For operations running KUKA, Fanuc, ABB, or other industrial platforms for milling, this means:

  • Tighter achievable tolerances on contoured surfaces and pocketed features — without slowing down

  • Reduced manual finishing after the robot pass — fewer witness marks, more consistent surface quality

  • Expanded part envelope — parts that previously required a CNC due to tolerance requirements may become viable on the robot cell

  • No hardware changes — deploys through the robot's existing command interface as a software layer

The economics are straightforward. If backlash is costing you a finishing pass, a manual correction step, or a reject rate on contoured parts, software compensation addresses the root cause at a fraction of the cost of upgrading the robot.

FAQ

Can software really fix a mechanical problem like backlash?
Software doesn't eliminate the physical gear clearance. It compensates for it by anticipating direction reversals and injecting corrective motion before the joint crosses the deadband. The gear teeth still have clearance — but the joint is already positioned to the correct side of the gap when the new motion begins.

Does backlash compensation work at high feed rates?
Yes. The compensation operates at the servo loop level, so it applies regardless of feed rate. In fact, higher speeds tend to benefit more because the dynamic effects of crossing the backlash gap — including the momentary loss of contact and the impact on re-engagement — are more pronounced at speed.

Which industrial robots have the worst backlash?
Backlash is present in every gear-driven robot. Robots with cycloidal or harmonic drive reducers (common in cobots and smaller industrial arms) tend to have less backlash than those with planetary gearboxes. However, even low-backlash drives accumulate wear over time. The actual backlash of a specific robot depends on its age, usage history, and maintenance. That's why per-robot calibration matters more than platform-level specifications.

How does this compare to buying a higher-precision robot?
A precision-grade industrial arm (e.g., KUKA KR Fortec Precision or Fanuc M-20iD/25 series) reduces backlash through tighter mechanical tolerances. The trade-off is cost — typically 2-4× the base model — and the backlash still increases with wear. Software compensation can be deployed on any arm and recalibrated as conditions change, at a fraction of the hardware upgrade cost.

Reforge Robotics builds control software that makes industrial robots more accurate. Backlash compensation is part of the Covalent Joint Tracker product. Book a demo to see it on your platform.

See what Reforge can improve on your robot

Bring one representative trajectory or error dataset. We’ll identify the relevant product, required inputs, and a bounded evaluation plan.

See what Reforge can improve on your robot

Bring one representative trajectory or error dataset. We’ll identify the relevant product, required inputs, and a bounded evaluation plan.

Resources

Reforge Robotics

100 Speedway Drive, Suite 445B

San Leandro, California 94609