The Secret Reforge Robotics Master Plan (just between you and me)

Nosa Edoimioya

Founder & CEO

The initial product of Reforge Robotics (“Reforge”) is anti-vibration software for robot arms called Covalent. It prevents vibration when cutting (or “machining”) metal and makes robots very accurate despite their lack of rigidity. However, some readers may not be aware of the fact that our long-term plan is to design low-cost manufacturing systems that use software to reduce the price of the hardware. This is because the overarching purpose of Reforge (and the reason I’m making it my life’s work) is to dramatically reduce the cost of manufacturing through this integrated design of machines.

Before starting Reforge, I worked on control software to help hundred-dollar 3D printers compete with more expensive 3D printers that cost thousands of dollars. The software uses a digital model of the machine to simulate manufacturing plans, then predict and correct errors in the plan before they affect the quality of the real-world process. Previously, 3D printer manufacturers added unnecessary mass to mechanically absorb (or “damp”) errors which increased the machine’s cost. Now, they can design lighter machines knowing that software can be used to compensate for errors.

We’re applying the same principle to the highest-value manufacturing industries, starting with the $100B industry of CNC machining. Covalent leverages the larger working volume and versatility of robot arms to make larger and more complex parts than existing CNC machines. Furthermore, and to our mission, robots are up to 10x cheaper than traditional manufacturing machines. Even so, some may question whether this is actually a good use of resources. Do we really need to drive down costs in manufacturing? Are robot arms the best form-factor for manufacturing machines?

Well, the answer is not really and no. However, that misses the point unless you understand the secret master plan alluded to above. The U.S. benefited from off-shoring manufacturing when low-cost overseas labor reduced costs. But as countries abroad become richer, their citizens will demand higher wages to support their middle-class lifestyle and costs will rise. The U.S. is also starting to worry about its reliance on manufacturing imports due to differences in geopolitical beliefs from foreign governments. Lower-income countries are hoping to fill the void for low-cost manufacturing, but achieving similar manufacturing quality requires high upfront investment in expensive equipment. By combining Covalent with low-cost manufacturing equipment (e.g. robots), we make fabricating high-quality products accessible to more people around the world. Needless to say, the production of high-quality goods in emerging markets for export will also lead to production of high-quality goods for domestic consumption to grow their economies.

As for the equipment question, we do not plan to use robot arms forever. Despite their versatility, robot arms are not the best form-factor for all forms of manufacturing. It’s also difficult to build digital models of robots because their manufacturers do not share critical information; we have to measure the models through robot calibration experiments. However, robots are a great hardware platform to build towards our goal because Covalent can be used to improve their machining quality while taking advantage of the other strengths alluded to above. They also provide more value for our customers by performing intelligent autonomous operations using AI (e.g., relocating parts, inspecting parts, etc.). For the record, we plan to saturate all tasks that are possible with robotic arms before building a new hardware platform.

Companies like Apple have shown that the best products have a tight integration between the software and hardware. Without giving away too much, I can say that our next manufacturing platform will combine the flexibility of robots and cost-optimized components of traditional manufacturing machines. It will be designed with the software in mind, allowing the hardware to be lighter-weight and less expensive. Knowledge of the machine’s parameters from inception further reduces the costs of software integration and hardware deployment. In keeping with a fast growing technology company, we will plow all free cash flow back into R&D for a long time to drive down costs and bring follow-on products to market as fast as possible.

Now I’d like to address a repeated argument against robotics — the elimination of jobs. If we succeed, we will heavily use automation both in our internal processes and in our products. Our automation will eliminate repetitive and dangerous manufacturing jobs, which will create temporary economic instability. However, factories are not desirable places to work and we plan to create new operations and software development jobs. For example, we will need people to calibrate robots and train AI models to keep the digital models up-to-date. Additionally, we will create several software applications for completing manufacturing tasks autonomously, but we cannot expect to cover everything. Independent developers who can write software applications for new manufacturing tasks on top of our platform will be in high demand. In short, this technological change will eliminate work but create new work to replace it, as has always been the case.

In line with the economic growth described above, several “accidental” products and companies will also be created as a result of achieving the plan. There will be software development companies created solely to develop and maintain software for manufacturing. There will also be large-scale and heavily-automated contract manufacturing companies, similar to the concept of ghost kitchens, that require only one or two employees to monitor the machines from their computers. We expect these “ghost manufacturers” to eventually dominate the industry. Last, but not least, the infrastructure necessary to transport manufactured goods in low-income countries will be built along with the logistics and coordination companies to deliver those goods. So, in short, the master plan is:


  1. Build software for robot arms to reduce the cost of metal machining equipment.

  2. Use that money to build software for robots to perform more manufacturing tasks.

  3. Use that money to build more affordable and versatile software-informed hardware.

  4. While doing the above, also create a marketplace of software applications for automating repetitive and dangerous manufacturing tasks.


Don’t tell anyone.
Nosa Edoimioya

Founder & CEO

Share post
Written by

Nosa Edoimioya, Founder & CEO

Published on

Continue Reading

9/13/26

The Backlash Problem in Robotic Machining and What Software Can Do About It

By Nosa Edoimioya

Gear backlash is one of the largest sources of dimensional error in robotic milling. Here's what it does to your parts and how software-based compensation addresses it.

Robotic milling is gaining ground as an alternative to 5-axis CNC for large, complex, and low-volume parts. A KUKA KR 500, Fanuc M-900, or ABB IRB 6700 costs a fraction of a comparable gantry mill, offers a larger work envelope, and can be repurposed across part families. But accuracy remains the constraint that keeps many machining operations from making the switch.

One of the biggest contributors to that accuracy gap is backlash — and it shows up exactly where milling demands the most from the robot: at direction changes.

What is backlash?

Backlash is the small amount of free movement between mating mechanical components — particularly gears — when the direction of motion reverses. Every gear-driven joint in a robot arm has some backlash. It's a function of manufacturing tolerances, gear geometry, wear, and assembly.

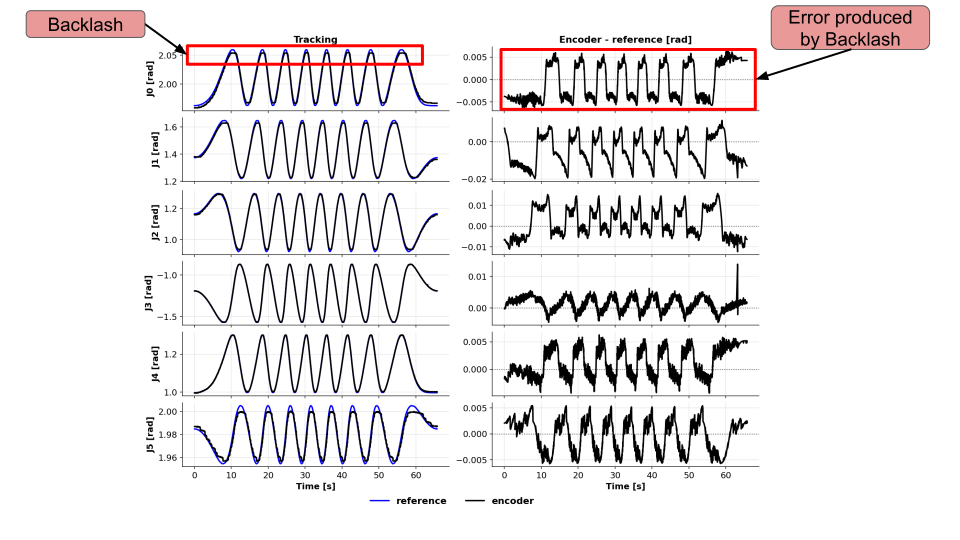
The mechanism is straightforward. When a motor drives a joint in one direction, the gear teeth are in contact on one side. When the motor reverses, it must cross the backlash gap — the clearance between teeth — before the gear teeth engage on the opposite side and the joint begins moving again. During that crossing, the motor moves but the joint does not. The encoder reads a position change that hasn't happened at the link.

For a typical industrial robot, backlash per joint ranges from 0.05° to 0.3°. That sounds small, but it compounds. A 0.1° backlash error at a single joint propagates through the kinematic chain. At the end of a 2-meter arm, it becomes 3 mm or more of TCP positioning error.

Joint encoder readings and tracking error during repeated direction reversals

Encoder readings and tracking error during repeated reversals in the Reforge validation test.

Why milling exposes backlash more than other applications

Pick-and-place, welding, and palletizing applications often mask backlash because the robot moves in long, sweeping arcs with few reversals. The joints move predominantly in one direction for each segment of the path.

Milling is different. A robot following a contour — profiling a turbine blade root, machining an aircraft skin panel, or cutting a composite layup — reverses joint directions constantly. Every concave-to-convex transition, every pocket corner, every change in contour curvature forces one or more joints through a reversal. Each reversal triggers the backlash gap.

The result is visible on the part:

  • Witness marks at direction changes — small steps or ridges where the tool path shifts by the backlash error as joints reverse

  • Dimensional errors on contoured surfaces — the TCP tracks inside or outside the programmed path depending on the direction of approach

  • Surface finish degradation at corners and transitions — the tool dwells or skips as joints cross their backlash gaps, producing chatter marks or uneven material removal

  • Non-repeatable errors — because backlash depends on the direction of the last motion, the same programmed path can produce different results depending on how the robot arrived at each point

These errors are distinct from the robot's static accuracy specification. A robot with ±0.05 mm repeatability can still produce 1-3 mm of path error during contour milling if backlash is uncompensated.

How shops deal with backlash today

The current approaches all involve working around the problem rather than solving it:

Approach

What it does

Trade-off

Reduce feed rate

Slows the robot to minimize dynamic effects

Cycle time increases 2-5x; backlash gap still exists, just crossed more slowly

Harmonic drives

Reduces the physical clearance between gear teeth

Higher cost per joint; Add compliance on the robot which limits payload

CAM path compensation

Creates a tool path that avoids joint reversals instead of compensating for the backlash

Do not work for the for tool paths where backlash can not be avoided

Finishing passes with manual correction

Operator measures and corrects after the robot pass

Defeats the purpose of automation; adds labor cost per part

Buy a more expensive robot

Higher-end platforms with tighter mechanical tolerances

KUKA or Fanuc precision series costs 2-4x more; still has backlash, just less of it

None of these approaches address the root cause: the controller doesn't know the backlash exists and can't compensate for it in real time.

How software-based backlash compensation works

Software-based compensation operates between the trajectory planner and the robot's native servo controller. It tracks the direction of motion at each joint and applies a correction when a reversal is detected.

The process has two parts:

Calibration. The system drives each joint through a structured sequence of reversals and measures the actual deadband — the angular gap where the motor moves but the link does not. This is done once per robot and captures the specific backlash characteristics of that arm, including any asymmetry between joints and any configuration-dependent variation.

Real-time compensation. During operation, the software monitors the commanded trajectory for direction reversals at each joint. When a reversal is detected, it injects a correction equal to the identified deadband, so the motor crosses the backlash gap before the joint is expected to begin moving in the new direction. The joint starts its new motion already in contact — eliminating the lag.

This layer works alongside existing accuracy improvements. Kinematic calibration corrects the robot's geometric model. Dynamic joint tracking compensates for compliance and lag. Backlash compensation handles the direction-reversal error that neither of those can address. Together, they reduce the total path error to a level that starts approaching what many milling operations require.

Measured results

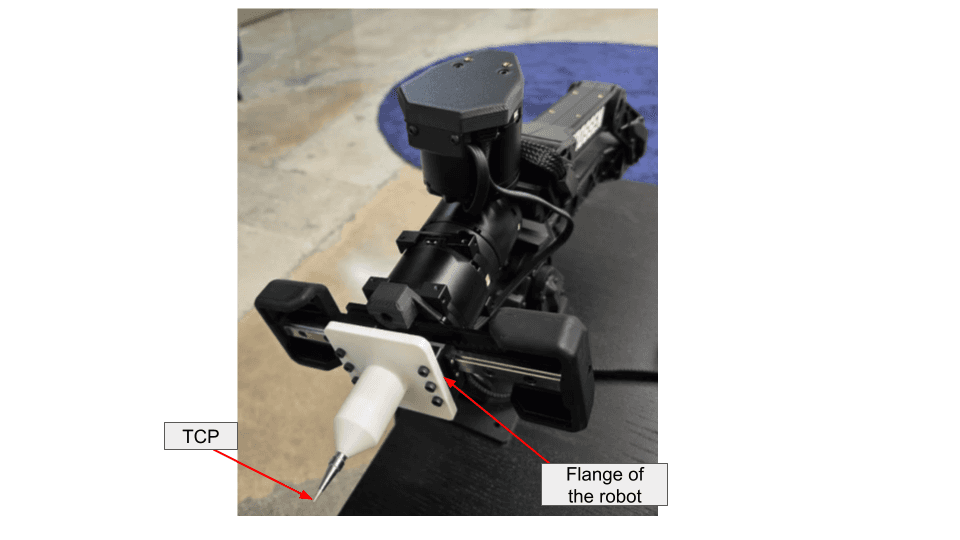
We validated backlash compensation on a trajectory specifically designed to force repeated joint reversals — the kind of multi-axis coordinated motion that robotic milling demands. The robot was commanded to track a circle with the flange center while holding the TCP fixed in Cartesian space, requiring all six joints to reverse direction continuously.

The validation setup: the metal tip marks the TCP, and the labeled flange follows the commanded circle.

Validation test setup with the metal-tip TCP and robot flange labeled

Metric

Without compensation

With compensation

Improvement

3-D TCP RMS tracking error

4.131 mm

0.878 mm

4.70×

All-joint RMS tracking error

0.593°

0.088°

6.75×

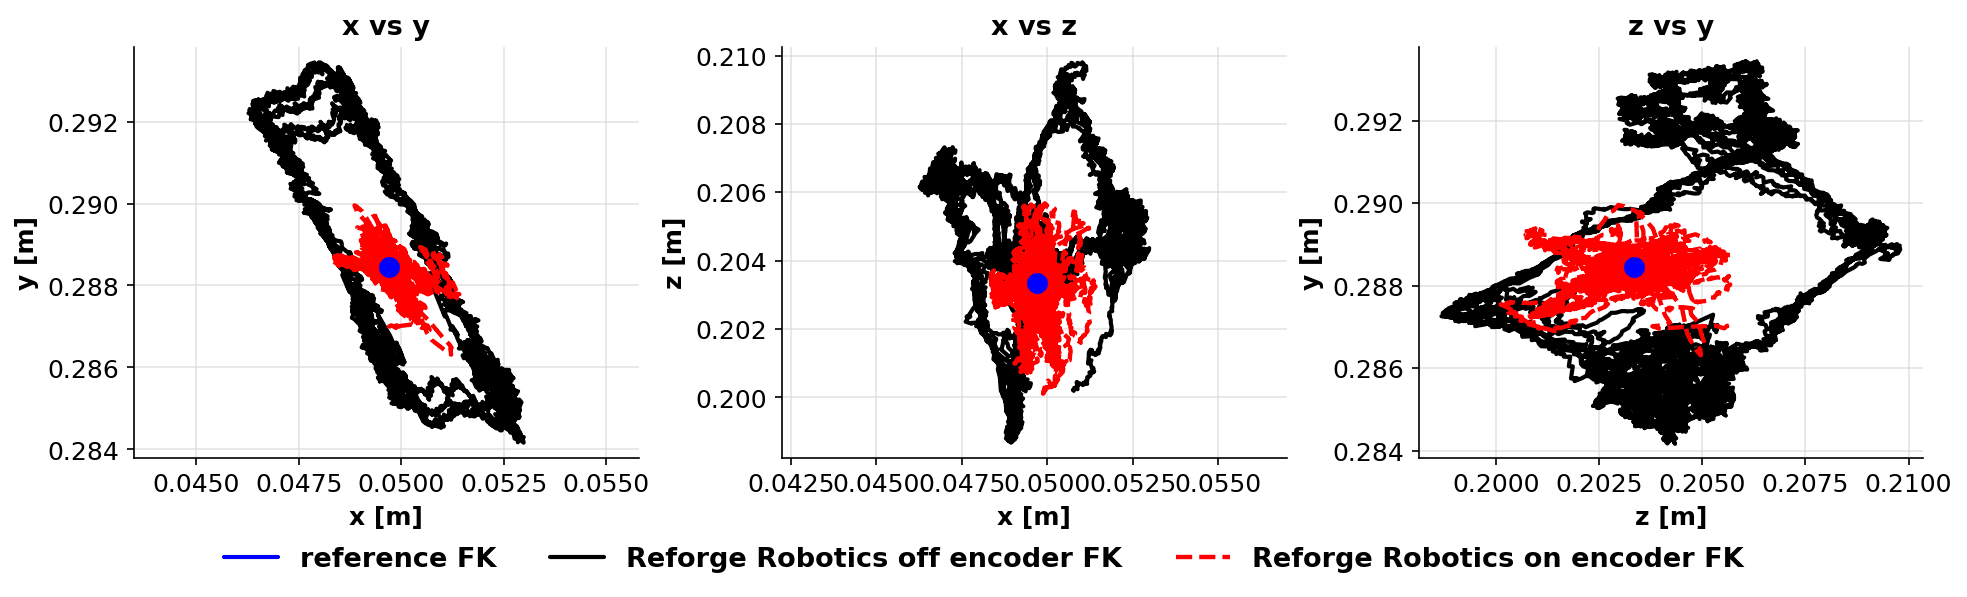
Estimated TCP position with Reforge software off and Joint Tracker plus Backlash Compensation on

Estimated TCP position in the validation test. Black is software off, red is Joint Tracker plus Backlash Compensation on, and blue marks the fixed reference. These measurements evaluate the combined software effect, not backlash compensation alone.

The per-joint results show that the compensation is effective across all joints, not just the ones with the largest backlash:

Joint

Without compensation

With compensation

Improvement

J0

0.330°

0.076°

4.37×

J1

0.948°

0.117°

8.11×

J2

0.927°

0.108°

8.59×

J3

0.320°

0.071°

4.52×

J4

0.319°

0.051°

6.26×

J5

0.204°

0.088°

2.32×

A 4.70× reduction in TCP tracking error during direction reversals changes what robotic milling can achieve. For a cell that was producing ±2 mm contour error, that drops to under ±0.5 mm — moving from rough machining territory into semi-finishing range without changing the robot, the spindle, or the CAM program.

What this means for your milling operation

Backlash compensation doesn't turn a robot arm into a 5-axis CNC. The robot still has structural compliance, thermal drift, and dynamic limitations that a purpose-built machine tool doesn't. But it removes one of the largest discrete error sources in robotic machining — and it does it through software, without mechanical modification.

For operations running KUKA, Fanuc, ABB, or other industrial platforms for milling, this means:

  • Tighter achievable tolerances on contoured surfaces and pocketed features — without slowing down

  • Reduced manual finishing after the robot pass — fewer witness marks, more consistent surface quality

  • Expanded part envelope — parts that previously required a CNC due to tolerance requirements may become viable on the robot cell

  • No hardware changes — deploys through the robot's existing command interface as a software layer

The economics are straightforward. If backlash is costing you a finishing pass, a manual correction step, or a reject rate on contoured parts, software compensation addresses the root cause at a fraction of the cost of upgrading the robot.

FAQ

Can software really fix a mechanical problem like backlash?
Software doesn't eliminate the physical gear clearance. It compensates for it by anticipating direction reversals and injecting corrective motion before the joint crosses the deadband. The gear teeth still have clearance — but the joint is already positioned to the correct side of the gap when the new motion begins.

Does backlash compensation work at high feed rates?
Yes. The compensation operates at the servo loop level, so it applies regardless of feed rate. In fact, higher speeds tend to benefit more because the dynamic effects of crossing the backlash gap — including the momentary loss of contact and the impact on re-engagement — are more pronounced at speed.

Which industrial robots have the worst backlash?
Backlash is present in every gear-driven robot. Robots with cycloidal or harmonic drive reducers (common in cobots and smaller industrial arms) tend to have less backlash than those with planetary gearboxes. However, even low-backlash drives accumulate wear over time. The actual backlash of a specific robot depends on its age, usage history, and maintenance. That's why per-robot calibration matters more than platform-level specifications.

How does this compare to buying a higher-precision robot?
A precision-grade industrial arm (e.g., KUKA KR Fortec Precision or Fanuc M-20iD/25 series) reduces backlash through tighter mechanical tolerances. The trade-off is cost — typically 2-4× the base model — and the backlash still increases with wear. Software compensation can be deployed on any arm and recalibrated as conditions change, at a fraction of the hardware upgrade cost.

Reforge Robotics builds control software that makes industrial robots more accurate. Backlash compensation is part of the Covalent Joint Tracker product. Book a demo to see it on your platform.

9/13/26

The Backlash Problem in Robotic Machining and What Software Can Do About It

By Nosa Edoimioya

Gear backlash is one of the largest sources of dimensional error in robotic milling. Here's what it does to your parts and how software-based compensation addresses it.

Robotic milling is gaining ground as an alternative to 5-axis CNC for large, complex, and low-volume parts. A KUKA KR 500, Fanuc M-900, or ABB IRB 6700 costs a fraction of a comparable gantry mill, offers a larger work envelope, and can be repurposed across part families. But accuracy remains the constraint that keeps many machining operations from making the switch.

One of the biggest contributors to that accuracy gap is backlash — and it shows up exactly where milling demands the most from the robot: at direction changes.

What is backlash?

Backlash is the small amount of free movement between mating mechanical components — particularly gears — when the direction of motion reverses. Every gear-driven joint in a robot arm has some backlash. It's a function of manufacturing tolerances, gear geometry, wear, and assembly.

The mechanism is straightforward. When a motor drives a joint in one direction, the gear teeth are in contact on one side. When the motor reverses, it must cross the backlash gap — the clearance between teeth — before the gear teeth engage on the opposite side and the joint begins moving again. During that crossing, the motor moves but the joint does not. The encoder reads a position change that hasn't happened at the link.

For a typical industrial robot, backlash per joint ranges from 0.05° to 0.3°. That sounds small, but it compounds. A 0.1° backlash error at a single joint propagates through the kinematic chain. At the end of a 2-meter arm, it becomes 3 mm or more of TCP positioning error.

Joint encoder readings and tracking error during repeated direction reversals

Encoder readings and tracking error during repeated reversals in the Reforge validation test.

Why milling exposes backlash more than other applications

Pick-and-place, welding, and palletizing applications often mask backlash because the robot moves in long, sweeping arcs with few reversals. The joints move predominantly in one direction for each segment of the path.

Milling is different. A robot following a contour — profiling a turbine blade root, machining an aircraft skin panel, or cutting a composite layup — reverses joint directions constantly. Every concave-to-convex transition, every pocket corner, every change in contour curvature forces one or more joints through a reversal. Each reversal triggers the backlash gap.

The result is visible on the part:

  • Witness marks at direction changes — small steps or ridges where the tool path shifts by the backlash error as joints reverse

  • Dimensional errors on contoured surfaces — the TCP tracks inside or outside the programmed path depending on the direction of approach

  • Surface finish degradation at corners and transitions — the tool dwells or skips as joints cross their backlash gaps, producing chatter marks or uneven material removal

  • Non-repeatable errors — because backlash depends on the direction of the last motion, the same programmed path can produce different results depending on how the robot arrived at each point

These errors are distinct from the robot's static accuracy specification. A robot with ±0.05 mm repeatability can still produce 1-3 mm of path error during contour milling if backlash is uncompensated.

How shops deal with backlash today

The current approaches all involve working around the problem rather than solving it:

Approach

What it does

Trade-off

Reduce feed rate

Slows the robot to minimize dynamic effects

Cycle time increases 2-5x; backlash gap still exists, just crossed more slowly

Harmonic drives

Reduces the physical clearance between gear teeth

Higher cost per joint; Add compliance on the robot which limits payload

CAM path compensation

Creates a tool path that avoids joint reversals instead of compensating for the backlash

Do not work for the for tool paths where backlash can not be avoided

Finishing passes with manual correction

Operator measures and corrects after the robot pass

Defeats the purpose of automation; adds labor cost per part

Buy a more expensive robot

Higher-end platforms with tighter mechanical tolerances

KUKA or Fanuc precision series costs 2-4x more; still has backlash, just less of it

None of these approaches address the root cause: the controller doesn't know the backlash exists and can't compensate for it in real time.

How software-based backlash compensation works

Software-based compensation operates between the trajectory planner and the robot's native servo controller. It tracks the direction of motion at each joint and applies a correction when a reversal is detected.

The process has two parts:

Calibration. The system drives each joint through a structured sequence of reversals and measures the actual deadband — the angular gap where the motor moves but the link does not. This is done once per robot and captures the specific backlash characteristics of that arm, including any asymmetry between joints and any configuration-dependent variation.

Real-time compensation. During operation, the software monitors the commanded trajectory for direction reversals at each joint. When a reversal is detected, it injects a correction equal to the identified deadband, so the motor crosses the backlash gap before the joint is expected to begin moving in the new direction. The joint starts its new motion already in contact — eliminating the lag.

This layer works alongside existing accuracy improvements. Kinematic calibration corrects the robot's geometric model. Dynamic joint tracking compensates for compliance and lag. Backlash compensation handles the direction-reversal error that neither of those can address. Together, they reduce the total path error to a level that starts approaching what many milling operations require.

Measured results

We validated backlash compensation on a trajectory specifically designed to force repeated joint reversals — the kind of multi-axis coordinated motion that robotic milling demands. The robot was commanded to track a circle with the flange center while holding the TCP fixed in Cartesian space, requiring all six joints to reverse direction continuously.

The validation setup: the metal tip marks the TCP, and the labeled flange follows the commanded circle.

Validation test setup with the metal-tip TCP and robot flange labeled

Metric

Without compensation

With compensation

Improvement

3-D TCP RMS tracking error

4.131 mm

0.878 mm

4.70×

All-joint RMS tracking error

0.593°

0.088°

6.75×

Estimated TCP position with Reforge software off and Joint Tracker plus Backlash Compensation on

Estimated TCP position in the validation test. Black is software off, red is Joint Tracker plus Backlash Compensation on, and blue marks the fixed reference. These measurements evaluate the combined software effect, not backlash compensation alone.

The per-joint results show that the compensation is effective across all joints, not just the ones with the largest backlash:

Joint

Without compensation

With compensation

Improvement

J0

0.330°

0.076°

4.37×

J1

0.948°

0.117°

8.11×

J2

0.927°

0.108°

8.59×

J3

0.320°

0.071°

4.52×

J4

0.319°

0.051°

6.26×

J5

0.204°

0.088°

2.32×

A 4.70× reduction in TCP tracking error during direction reversals changes what robotic milling can achieve. For a cell that was producing ±2 mm contour error, that drops to under ±0.5 mm — moving from rough machining territory into semi-finishing range without changing the robot, the spindle, or the CAM program.

What this means for your milling operation

Backlash compensation doesn't turn a robot arm into a 5-axis CNC. The robot still has structural compliance, thermal drift, and dynamic limitations that a purpose-built machine tool doesn't. But it removes one of the largest discrete error sources in robotic machining — and it does it through software, without mechanical modification.

For operations running KUKA, Fanuc, ABB, or other industrial platforms for milling, this means:

  • Tighter achievable tolerances on contoured surfaces and pocketed features — without slowing down

  • Reduced manual finishing after the robot pass — fewer witness marks, more consistent surface quality

  • Expanded part envelope — parts that previously required a CNC due to tolerance requirements may become viable on the robot cell

  • No hardware changes — deploys through the robot's existing command interface as a software layer

The economics are straightforward. If backlash is costing you a finishing pass, a manual correction step, or a reject rate on contoured parts, software compensation addresses the root cause at a fraction of the cost of upgrading the robot.

FAQ

Can software really fix a mechanical problem like backlash?
Software doesn't eliminate the physical gear clearance. It compensates for it by anticipating direction reversals and injecting corrective motion before the joint crosses the deadband. The gear teeth still have clearance — but the joint is already positioned to the correct side of the gap when the new motion begins.

Does backlash compensation work at high feed rates?
Yes. The compensation operates at the servo loop level, so it applies regardless of feed rate. In fact, higher speeds tend to benefit more because the dynamic effects of crossing the backlash gap — including the momentary loss of contact and the impact on re-engagement — are more pronounced at speed.

Which industrial robots have the worst backlash?
Backlash is present in every gear-driven robot. Robots with cycloidal or harmonic drive reducers (common in cobots and smaller industrial arms) tend to have less backlash than those with planetary gearboxes. However, even low-backlash drives accumulate wear over time. The actual backlash of a specific robot depends on its age, usage history, and maintenance. That's why per-robot calibration matters more than platform-level specifications.

How does this compare to buying a higher-precision robot?
A precision-grade industrial arm (e.g., KUKA KR Fortec Precision or Fanuc M-20iD/25 series) reduces backlash through tighter mechanical tolerances. The trade-off is cost — typically 2-4× the base model — and the backlash still increases with wear. Software compensation can be deployed on any arm and recalibrated as conditions change, at a fraction of the hardware upgrade cost.

Reforge Robotics builds control software that makes industrial robots more accurate. Backlash compensation is part of the Covalent Joint Tracker product. Book a demo to see it on your platform.

Industrial robot arm probing a compact kinematic calibration fixture

9/11/26

10 Minutes to 3-5x Better Accuracy: How Kinematic Calibration Works

By Iago Alves Pereira

What happens during a KineCal calibration — and why it takes minutes instead of days.

Kinematic calibration has historically been a specialist operation. A laser tracker, a trained metrology engineer, hours of setup, and a production line taken offline. The result is sub-millimeter accuracy that lasts until the robot drifts — and then you do it again.

We built KineCal to deliver comparable results in roughly 10 minutes, using the robot's own sensors and a calibration fixture that costs under $35. This post walks through what happens during those 10 minutes, how the system identification works, and what the measured results look like.

The problem KineCal solves

Every robot arm ships with a kinematic model — the mathematical description of its geometry that the controller uses to convert between joint angles and Cartesian positions. Link lengths, joint axis orientations, offsets, frame alignments.

The model is based on nominal design parameters. The physical machine is not nominal. Manufacturing tolerances, assembly variation, installation effects, and wear all create discrepancies between the model and the real geometry. The controller doesn't know the difference. It plans motions using an idealized machine, and the real machine deviates.

The result is positional error — typically 0.6 to 1.0mm on a standard 6-axis arm out of the box. That's the gap between where the controller thinks the TCP is and where it actually is.

KineCal identifies the real kinematic parameters from measured data and replaces the nominal model with one that matches the specific robot as installed.

What happens in 10 minutes

The calibration process has three steps. The first two run sequentially on the robot. The third runs in the cloud.

Step 1: Fixture setup (~2 minutes). The operator places a calibration fixture in the robot's workspace. The fixture is built from commodity hardware — an off-the-shelf bracket and reference features that can be assembled in under five minutes the first time, and under two minutes after that. No precision alignment is required. The system identifies the fixture's location from the measurement data, so approximate placement is sufficient.

The fixture provides known geometric constraints that the calibration algorithm uses to separate the robot's kinematic parameters from the fixture's position. In practice, this means the operator doesn't need to know the fixture's exact location — only that it's rigidly placed within reach.

Step 2: Automated measurement routine (~5 minutes). The operator runs a single command through the Reforge SDK. The robot executes a structured sequence of movements, approaching the calibration fixture from multiple configurations. At each configuration, the robot's joint encoders record the joint angles while the TCP contacts or approaches the fixture's reference features.

The measurement routine is designed to maximize observability of the kinematic parameters. It exercises the robot through configurations that expose each parameter's effect on TCP position — varying joint angles, approach directions, and arm configurations to decorrelate the parameters during identification.

The routine is fully automated. The operator starts it and waits. No manual teaching, no jogging, no point-by-point recording.

Step 3: Model identification (~3 minutes, cloud). The measurement data is uploaded to the Reforge API. The server runs a system identification algorithm that fits a kinematic model to the observed data.

The algorithm solves for the actual DH parameters — link lengths, joint offsets, twist angles, and link offsets — that best explain the measured joint configurations given the geometric constraints of the fixture. This is an optimization problem: find the kinematic parameters that minimize the residual error between the model's predicted TCP positions and the observed measurements.

The output is a calibrated kinematic model specific to that robot. It downloads and deploys as a software update through the SDK.

What the results look like

We've validated KineCal internally across multiple robot platforms. The consistent result is a 3x to 5x improvement in positional accuracy.

Before calibration: Typical TCP positional error of 0.6 to 1.0mm. This is the error from the nominal kinematic model — the gap between designed geometry and actual geometry.

After calibration: TCP positional error of 0.18 to 0.21mm. This is close to the repeatability limit of the robots we've tested — meaning the calibrated model has eliminated effectively all of the systematic kinematic error, and the remaining error is dominated by the robot's own mechanical precision.

The improvement ratio depends on how far the specific robot's geometry has drifted from nominal. A brand-new robot with tight manufacturing tolerances might start at 0.5mm and reach 0.18mm — roughly a 3x improvement. A robot with accumulated wear, a replaced joint, or a significant installation offset might start at 1.5mm and reach 0.20mm — closer to 7x.

The calibrated accuracy is consistent across the workspace. Unlike touch-up programming, which corrects individual waypoints, kinematic calibration corrects the underlying model. Every position the robot moves to benefits from the correction, not just the positions that were explicitly taught.

How calibration times compare across products

KineCal is one of three calibration products in the Reforge platform. The calibration time varies by product because each captures different properties of the robot:

  • Kinematic Calibration (KineCal): Static geometry — link lengths, joint offsets, frame alignments. Calibration time: ~10 minutes.

  • Joint Tracker: Per-joint dynamic response — lag, resonance, damping. Calibration time: ~5-10 minutes.

  • Vibration Compensation (Shaper): Full structural frequency response — how the robot amplifies and dampens motion across its frequency spectrum. Calibration time: up to 48 hours of data collection.

The vibration compensation number deserves context. The 48 hours of data collection can be spread across overnight runs over the course of a week. The robot collects calibration data during periods when it would otherwise be idle. It doesn't require dedicated downtime — the calibration runs alongside or in between production shifts.

The kinematic calibration and Joint Tracker calibrations are the fast ones. Both are designed to run during a scheduled maintenance window or as part of initial commissioning. Combined, they take under 20 minutes and deliver both the geometric correction (KineCal) and the dynamic feedforward compensation (Joint Tracker).

No laser tracker required

Traditional kinematic calibration depends on external metrology — typically a laser tracker system costing $50,000 to $150,000, plus a trained operator. The laser tracker provides ground-truth TCP measurements that the calibration algorithm uses to identify the kinematic parameters.

KineCal replaces the external measurement system with a structured fixture and the robot's own sensors. The geometric constraints of the fixture provide the equivalent of ground-truth reference — not by measuring the TCP's absolute position in space, but by providing known geometric relationships that the optimization algorithm uses to solve for the kinematic parameters.

The trade-off is straightforward. A laser tracker gives you absolute accuracy referenced to a calibrated metrology instrument. KineCal gives you accuracy referenced to the geometric constraints of a commodity fixture. For applications that require traceable metrology — aerospace machining, medical device manufacturing — the laser tracker is the right tool.

For everything else — and that's the majority of robotic applications — KineCal delivers comparable results at a fraction of the cost, time, and expertise. A $35 fixture, 10 minutes of robot time, and no metrology specialist.

When to calibrate

The question of when to calibrate comes up in every evaluation. The practical answer: calibrate at commissioning, and recalibrate on a schedule matched to your accuracy requirements.

For most applications, every six months is a reasonable starting cadence. Robots in heavy use, high-precision applications, or environments with significant thermal cycling benefit from more frequent calibration — monthly or even after every tool change.

The key enabler is that 10-minute calibration time. When calibration is fast enough to fit into a maintenance window, it stops being a special event and becomes a routine step. The economics of calibration change fundamentally when the process takes minutes instead of days.

Reforge Robotics builds open-source motion control software that makes robot calibration fast, affordable, and repeatable.

Industrial robot arm probing a compact kinematic calibration fixture

9/11/26

10 Minutes to 3-5x Better Accuracy: How Kinematic Calibration Works

By Iago Alves Pereira

What happens during a KineCal calibration — and why it takes minutes instead of days.

Kinematic calibration has historically been a specialist operation. A laser tracker, a trained metrology engineer, hours of setup, and a production line taken offline. The result is sub-millimeter accuracy that lasts until the robot drifts — and then you do it again.

We built KineCal to deliver comparable results in roughly 10 minutes, using the robot's own sensors and a calibration fixture that costs under $35. This post walks through what happens during those 10 minutes, how the system identification works, and what the measured results look like.

The problem KineCal solves

Every robot arm ships with a kinematic model — the mathematical description of its geometry that the controller uses to convert between joint angles and Cartesian positions. Link lengths, joint axis orientations, offsets, frame alignments.

The model is based on nominal design parameters. The physical machine is not nominal. Manufacturing tolerances, assembly variation, installation effects, and wear all create discrepancies between the model and the real geometry. The controller doesn't know the difference. It plans motions using an idealized machine, and the real machine deviates.

The result is positional error — typically 0.6 to 1.0mm on a standard 6-axis arm out of the box. That's the gap between where the controller thinks the TCP is and where it actually is.

KineCal identifies the real kinematic parameters from measured data and replaces the nominal model with one that matches the specific robot as installed.

What happens in 10 minutes

The calibration process has three steps. The first two run sequentially on the robot. The third runs in the cloud.

Step 1: Fixture setup (~2 minutes). The operator places a calibration fixture in the robot's workspace. The fixture is built from commodity hardware — an off-the-shelf bracket and reference features that can be assembled in under five minutes the first time, and under two minutes after that. No precision alignment is required. The system identifies the fixture's location from the measurement data, so approximate placement is sufficient.

The fixture provides known geometric constraints that the calibration algorithm uses to separate the robot's kinematic parameters from the fixture's position. In practice, this means the operator doesn't need to know the fixture's exact location — only that it's rigidly placed within reach.

Step 2: Automated measurement routine (~5 minutes). The operator runs a single command through the Reforge SDK. The robot executes a structured sequence of movements, approaching the calibration fixture from multiple configurations. At each configuration, the robot's joint encoders record the joint angles while the TCP contacts or approaches the fixture's reference features.

The measurement routine is designed to maximize observability of the kinematic parameters. It exercises the robot through configurations that expose each parameter's effect on TCP position — varying joint angles, approach directions, and arm configurations to decorrelate the parameters during identification.

The routine is fully automated. The operator starts it and waits. No manual teaching, no jogging, no point-by-point recording.

Step 3: Model identification (~3 minutes, cloud). The measurement data is uploaded to the Reforge API. The server runs a system identification algorithm that fits a kinematic model to the observed data.

The algorithm solves for the actual DH parameters — link lengths, joint offsets, twist angles, and link offsets — that best explain the measured joint configurations given the geometric constraints of the fixture. This is an optimization problem: find the kinematic parameters that minimize the residual error between the model's predicted TCP positions and the observed measurements.

The output is a calibrated kinematic model specific to that robot. It downloads and deploys as a software update through the SDK.

What the results look like

We've validated KineCal internally across multiple robot platforms. The consistent result is a 3x to 5x improvement in positional accuracy.

Before calibration: Typical TCP positional error of 0.6 to 1.0mm. This is the error from the nominal kinematic model — the gap between designed geometry and actual geometry.

After calibration: TCP positional error of 0.18 to 0.21mm. This is close to the repeatability limit of the robots we've tested — meaning the calibrated model has eliminated effectively all of the systematic kinematic error, and the remaining error is dominated by the robot's own mechanical precision.

The improvement ratio depends on how far the specific robot's geometry has drifted from nominal. A brand-new robot with tight manufacturing tolerances might start at 0.5mm and reach 0.18mm — roughly a 3x improvement. A robot with accumulated wear, a replaced joint, or a significant installation offset might start at 1.5mm and reach 0.20mm — closer to 7x.

The calibrated accuracy is consistent across the workspace. Unlike touch-up programming, which corrects individual waypoints, kinematic calibration corrects the underlying model. Every position the robot moves to benefits from the correction, not just the positions that were explicitly taught.

How calibration times compare across products

KineCal is one of three calibration products in the Reforge platform. The calibration time varies by product because each captures different properties of the robot:

  • Kinematic Calibration (KineCal): Static geometry — link lengths, joint offsets, frame alignments. Calibration time: ~10 minutes.

  • Joint Tracker: Per-joint dynamic response — lag, resonance, damping. Calibration time: ~5-10 minutes.

  • Vibration Compensation (Shaper): Full structural frequency response — how the robot amplifies and dampens motion across its frequency spectrum. Calibration time: up to 48 hours of data collection.

The vibration compensation number deserves context. The 48 hours of data collection can be spread across overnight runs over the course of a week. The robot collects calibration data during periods when it would otherwise be idle. It doesn't require dedicated downtime — the calibration runs alongside or in between production shifts.

The kinematic calibration and Joint Tracker calibrations are the fast ones. Both are designed to run during a scheduled maintenance window or as part of initial commissioning. Combined, they take under 20 minutes and deliver both the geometric correction (KineCal) and the dynamic feedforward compensation (Joint Tracker).

No laser tracker required

Traditional kinematic calibration depends on external metrology — typically a laser tracker system costing $50,000 to $150,000, plus a trained operator. The laser tracker provides ground-truth TCP measurements that the calibration algorithm uses to identify the kinematic parameters.

KineCal replaces the external measurement system with a structured fixture and the robot's own sensors. The geometric constraints of the fixture provide the equivalent of ground-truth reference — not by measuring the TCP's absolute position in space, but by providing known geometric relationships that the optimization algorithm uses to solve for the kinematic parameters.

The trade-off is straightforward. A laser tracker gives you absolute accuracy referenced to a calibrated metrology instrument. KineCal gives you accuracy referenced to the geometric constraints of a commodity fixture. For applications that require traceable metrology — aerospace machining, medical device manufacturing — the laser tracker is the right tool.

For everything else — and that's the majority of robotic applications — KineCal delivers comparable results at a fraction of the cost, time, and expertise. A $35 fixture, 10 minutes of robot time, and no metrology specialist.

When to calibrate

The question of when to calibrate comes up in every evaluation. The practical answer: calibrate at commissioning, and recalibrate on a schedule matched to your accuracy requirements.

For most applications, every six months is a reasonable starting cadence. Robots in heavy use, high-precision applications, or environments with significant thermal cycling benefit from more frequent calibration — monthly or even after every tool change.

The key enabler is that 10-minute calibration time. When calibration is fast enough to fit into a maintenance window, it stops being a special event and becomes a routine step. The economics of calibration change fundamentally when the process takes minutes instead of days.

Reforge Robotics builds open-source motion control software that makes robot calibration fast, affordable, and repeatable.

Robot in an automotive plant

9/4/26

Do You Need to Calibrate Every Robot?

By Iago Alves Pereira

When a model trained on one machine can cover the fleet — and when it can't.

One of the first questions we hear from teams evaluating Reforge is about scaling: if I calibrate one robot, do I need to calibrate every other robot of the same model?

The short answer is no — with a caveat that matters. A model trained on one unit of a given SKU will transfer to other units of the same SKU and deliver roughly 90% of the calibrated performance. The remaining 10% is the gap between nominally identical and physically identical. Whether that gap matters depends on your application.

This post explains what transfers across robots, what doesn't, and how to decide the right calibration strategy for your fleet.

What the model actually captures

When we calibrate a robot, we're building a mathematical model of how that specific machine behaves. For kinematic calibration, the model captures the real geometry — actual link lengths, joint axis orientations, offsets, and frame alignments as measured on the physical hardware. For dynamic calibration (vibration compensation and feedforward control), the model captures frequency response characteristics — how the robot amplifies or dampens motion at different frequencies, with what lag, and with what coupling between joints.

These properties come from two sources: the design of the robot and the specific physical instance.

Design-level properties are shared across all units of a SKU. The nominal link lengths, the gear ratios, the actuator types, the structural topology — these are determined by the engineering drawings and are consistent across the production run. A model captures these faithfully, and they transfer perfectly.

Instance-level properties vary from unit to unit. Manufacturing tolerances in link dimensions, joint axis alignment, gearbox backlash, bearing preload, cable routing, and assembly torques. These are small variations — typically tenths of a millimeter in geometry and single-digit percentage differences in dynamic parameters — but they compound through the kinematic chain and produce measurably different behavior at the TCP.

The 90% transfer

When you apply a model trained on Robot A to Robot B of the same SKU, you get the design-level correction for free. The systematic errors that all units of that model share — the difference between the nominal kinematic parameters and the actual average for that production run — are captured and corrected.

That correction alone is significant. On the platforms we've validated, the design-level error accounts for the majority of the total kinematic error. Correcting it brings most units from roughly 0.6-1.0mm of positional error down to the 0.2-0.3mm range.

The remaining instance-level error — the per-unit variation from manufacturing tolerances — is what the transferred model doesn't capture. It's real, but it's small relative to the uncalibrated baseline. This is what we mean by 90% of the performance: the transferred model eliminates most of the error, but the last increment of accuracy requires per-unit calibration.

When 90% is enough

For many applications, a transferred model is the right answer.

If your tolerance budget is 1mm and the uncalibrated robot has 2-3mm of error, a transferred model that brings every unit down to 0.2-0.3mm gives you substantial margin. You don't need per-unit calibration. You need one calibration per SKU, and every robot benefits.

This is the scaling story that matters for fleet operators. Calibrate one unit. Deploy the model across all units of that SKU. The marginal cost of adding the next robot is zero calibration time.

Applications where this works well:

  • Pick-and-place with tolerances above 0.5mm. The transferred model puts every unit well inside the budget.

  • Palletizing and machine tending. These applications are tolerance-friendly and benefit primarily from the speed improvement that vibration compensation provides. The dynamic model transfers well across units because the structural design is shared.

  • Visual inspection at fixed stations. If the robot moves to inspection positions and stops, the accuracy requirement is at the waypoints only. A transferred kinematic model is usually sufficient.

When you need per-unit calibration

The 10% gap matters when your application consumes the full accuracy budget.

If your tolerance is 0.3mm and the transferred model delivers 0.2-0.3mm, you're operating at the margin. Some units will pass. Others won't. The variation between units becomes the limiting factor.

Per-unit calibration closes the gap. Calibrating the specific robot identifies its actual geometry — not the average geometry of its SKU — and produces a model that reaches the platform's accuracy floor. On our validated platforms, that floor is approximately 0.18-0.21mm.

Applications where per-unit calibration matters:

  • Precision assembly and insertion tasks. Connector insertion, pin alignment, and similar operations where the tolerance is smaller than the per-unit variation.

  • Offline programming without touch-up. If the goal is to generate paths in simulation and run them on the real robot without manual correction, per-unit accuracy is the requirement. The transferred model gets close. Per-unit calibration eliminates the remaining teaching step.

  • Multi-robot coordination. When two or more robots need to agree on the location of a shared workspace, their individual kinematic errors need to be independently corrected. A shared model doesn't resolve the relative error between units.

  • Quality-critical applications where out-of-tolerance means scrap — welding, dispensing, laser processing — and the cost of a single bad part exceeds the cost of calibrating the robot.

The practical approach

The calibration strategy that makes sense for most fleets is a two-tier approach.

Tier 1: One model per SKU. Calibrate one robot of each model in your fleet. Deploy that model across all units of the same SKU. This covers the design-level error and handles the majority of the accuracy improvement with minimal effort.

Tier 2: Per-unit calibration where needed. For robots in precision applications, or for units that show higher-than-expected error with the transferred model, run per-unit calibration. The process takes roughly 10 minutes for kinematic calibration. It can be integrated into commissioning workflows or run during scheduled maintenance.The process for other products is similar because our system fine-tunes the base model, combining the initial data with a smaller dataset.

The key advantage of this approach is that per-unit calibration is not expensive. With Reforge's KineCal, the calibration fixture costs under $35 in commodity hardware. The measurement routine is automated through the SDK. The model fitting runs in the cloud. An operator can calibrate a robot without metrology expertise or specialized equipment.

When calibration takes 10 minutes and costs effectively nothing in equipment, the question shifts from "can we afford to calibrate every robot?" to "is there a reason not to?"

Recalibration and drift

The transferability question also has a time dimension. A model trained today captures the robot's current state. Over months, mechanical wear changes the properties — gearbox backlash increases, bearings develop play, structural characteristics shift.

We recommend recalibrating at a minimum every six months. Robots in heavy-use or high-precision applications benefit from more frequent calibration — even as often as monthly. The calibration process is designed to run during scheduled downtime or overnight without taking the robot offline during production.

A continuous monitoring feature is on our roadmap that would use ongoing data collection to detect drift and trigger recalibration automatically. Until then, scheduled recalibration at a cadence matched to your application's tolerance budget is the practical approach.

The bottom line

You don't need to calibrate every robot from day one. A model trained on one unit covers the fleet at roughly 90% of the calibrated performance. For most applications, that's more than sufficient.

Where the last 10% matters — precision assembly, offline programming, multi-robot coordination — per-unit calibration/fine-tuning closes the gap in about 10 minutes with no specialized equipment.

The practical strategy: calibrate one per SKU as the baseline, then per-unit where the application demands it. Scale the fleet first. Calibrate precisely where it counts.

Reforge Robotics builds advanced motion control software that makes robot calibration fast, affordable, and repeatable.

Robot in an automotive plant

9/4/26

Do You Need to Calibrate Every Robot?

By Iago Alves Pereira

When a model trained on one machine can cover the fleet — and when it can't.

One of the first questions we hear from teams evaluating Reforge is about scaling: if I calibrate one robot, do I need to calibrate every other robot of the same model?

The short answer is no — with a caveat that matters. A model trained on one unit of a given SKU will transfer to other units of the same SKU and deliver roughly 90% of the calibrated performance. The remaining 10% is the gap between nominally identical and physically identical. Whether that gap matters depends on your application.

This post explains what transfers across robots, what doesn't, and how to decide the right calibration strategy for your fleet.

What the model actually captures

When we calibrate a robot, we're building a mathematical model of how that specific machine behaves. For kinematic calibration, the model captures the real geometry — actual link lengths, joint axis orientations, offsets, and frame alignments as measured on the physical hardware. For dynamic calibration (vibration compensation and feedforward control), the model captures frequency response characteristics — how the robot amplifies or dampens motion at different frequencies, with what lag, and with what coupling between joints.

These properties come from two sources: the design of the robot and the specific physical instance.

Design-level properties are shared across all units of a SKU. The nominal link lengths, the gear ratios, the actuator types, the structural topology — these are determined by the engineering drawings and are consistent across the production run. A model captures these faithfully, and they transfer perfectly.

Instance-level properties vary from unit to unit. Manufacturing tolerances in link dimensions, joint axis alignment, gearbox backlash, bearing preload, cable routing, and assembly torques. These are small variations — typically tenths of a millimeter in geometry and single-digit percentage differences in dynamic parameters — but they compound through the kinematic chain and produce measurably different behavior at the TCP.

The 90% transfer

When you apply a model trained on Robot A to Robot B of the same SKU, you get the design-level correction for free. The systematic errors that all units of that model share — the difference between the nominal kinematic parameters and the actual average for that production run — are captured and corrected.

That correction alone is significant. On the platforms we've validated, the design-level error accounts for the majority of the total kinematic error. Correcting it brings most units from roughly 0.6-1.0mm of positional error down to the 0.2-0.3mm range.

The remaining instance-level error — the per-unit variation from manufacturing tolerances — is what the transferred model doesn't capture. It's real, but it's small relative to the uncalibrated baseline. This is what we mean by 90% of the performance: the transferred model eliminates most of the error, but the last increment of accuracy requires per-unit calibration.

When 90% is enough

For many applications, a transferred model is the right answer.

If your tolerance budget is 1mm and the uncalibrated robot has 2-3mm of error, a transferred model that brings every unit down to 0.2-0.3mm gives you substantial margin. You don't need per-unit calibration. You need one calibration per SKU, and every robot benefits.

This is the scaling story that matters for fleet operators. Calibrate one unit. Deploy the model across all units of that SKU. The marginal cost of adding the next robot is zero calibration time.

Applications where this works well:

  • Pick-and-place with tolerances above 0.5mm. The transferred model puts every unit well inside the budget.

  • Palletizing and machine tending. These applications are tolerance-friendly and benefit primarily from the speed improvement that vibration compensation provides. The dynamic model transfers well across units because the structural design is shared.

  • Visual inspection at fixed stations. If the robot moves to inspection positions and stops, the accuracy requirement is at the waypoints only. A transferred kinematic model is usually sufficient.

When you need per-unit calibration

The 10% gap matters when your application consumes the full accuracy budget.

If your tolerance is 0.3mm and the transferred model delivers 0.2-0.3mm, you're operating at the margin. Some units will pass. Others won't. The variation between units becomes the limiting factor.

Per-unit calibration closes the gap. Calibrating the specific robot identifies its actual geometry — not the average geometry of its SKU — and produces a model that reaches the platform's accuracy floor. On our validated platforms, that floor is approximately 0.18-0.21mm.

Applications where per-unit calibration matters:

  • Precision assembly and insertion tasks. Connector insertion, pin alignment, and similar operations where the tolerance is smaller than the per-unit variation.

  • Offline programming without touch-up. If the goal is to generate paths in simulation and run them on the real robot without manual correction, per-unit accuracy is the requirement. The transferred model gets close. Per-unit calibration eliminates the remaining teaching step.

  • Multi-robot coordination. When two or more robots need to agree on the location of a shared workspace, their individual kinematic errors need to be independently corrected. A shared model doesn't resolve the relative error between units.

  • Quality-critical applications where out-of-tolerance means scrap — welding, dispensing, laser processing — and the cost of a single bad part exceeds the cost of calibrating the robot.

The practical approach

The calibration strategy that makes sense for most fleets is a two-tier approach.

Tier 1: One model per SKU. Calibrate one robot of each model in your fleet. Deploy that model across all units of the same SKU. This covers the design-level error and handles the majority of the accuracy improvement with minimal effort.

Tier 2: Per-unit calibration where needed. For robots in precision applications, or for units that show higher-than-expected error with the transferred model, run per-unit calibration. The process takes roughly 10 minutes for kinematic calibration. It can be integrated into commissioning workflows or run during scheduled maintenance.The process for other products is similar because our system fine-tunes the base model, combining the initial data with a smaller dataset.

The key advantage of this approach is that per-unit calibration is not expensive. With Reforge's KineCal, the calibration fixture costs under $35 in commodity hardware. The measurement routine is automated through the SDK. The model fitting runs in the cloud. An operator can calibrate a robot without metrology expertise or specialized equipment.

When calibration takes 10 minutes and costs effectively nothing in equipment, the question shifts from "can we afford to calibrate every robot?" to "is there a reason not to?"

Recalibration and drift

The transferability question also has a time dimension. A model trained today captures the robot's current state. Over months, mechanical wear changes the properties — gearbox backlash increases, bearings develop play, structural characteristics shift.

We recommend recalibrating at a minimum every six months. Robots in heavy-use or high-precision applications benefit from more frequent calibration — even as often as monthly. The calibration process is designed to run during scheduled downtime or overnight without taking the robot offline during production.

A continuous monitoring feature is on our roadmap that would use ongoing data collection to detect drift and trigger recalibration automatically. Until then, scheduled recalibration at a cadence matched to your application's tolerance budget is the practical approach.

The bottom line

You don't need to calibrate every robot from day one. A model trained on one unit covers the fleet at roughly 90% of the calibrated performance. For most applications, that's more than sufficient.

Where the last 10% matters — precision assembly, offline programming, multi-robot coordination — per-unit calibration/fine-tuning closes the gap in about 10 minutes with no specialized equipment.

The practical strategy: calibrate one per SKU as the baseline, then per-unit where the application demands it. Scale the fleet first. Calibrate precisely where it counts.

Reforge Robotics builds advanced motion control software that makes robot calibration fast, affordable, and repeatable.

See what Reforge can improve on your robot

Bring one representative trajectory or error dataset. We’ll identify the relevant product, required inputs, and a bounded evaluation plan.

See what Reforge can improve on your robot

Bring one representative trajectory or error dataset. We’ll identify the relevant product, required inputs, and a bounded evaluation plan.

Reforge Robotics

100 Speedway Drive, Suite 445B

San Leandro, California 94609