The Backlash Problem in Robotic Machining and What Software Can Do About It

Nosa Edoimioya
Founder & CEO

Gear backlash is one of the largest sources of dimensional error in robotic milling. Here’s what it does to your parts and how software-based compensation addresses it.
Robotic milling is gaining ground as an alternative to 5-axis CNC for large, complex, and low-volume parts. A KUKA KR 500, Fanuc M-900, or ABB IRB 6700 costs a fraction of a comparable gantry mill, offers a larger work envelope, and can be repurposed across part families. But accuracy remains the constraint that keeps many machining operations from making the switch.
One of the biggest contributors to that accuracy gap is backlash — and it shows up exactly where milling demands the most from the robot: at direction changes.
What is backlash?
Backlash is the small amount of free movement between mating mechanical components — particularly gears — when the direction of motion reverses. Every gear-driven joint in a robot arm has some backlash. It’s a function of manufacturing tolerances, gear geometry, wear, and assembly.
The mechanism is straightforward. When a motor drives a joint in one direction, the gear teeth are in contact on one side. When the motor reverses, it must cross the backlash gap — the clearance between teeth — before the gear teeth engage on the opposite side and the joint begins moving again. During that crossing, the motor moves but the joint does not. The encoder reads a position change that hasn’t happened at the link.
For a typical industrial robot, backlash per joint ranges from 0.05° to 0.3°. That sounds small, but it compounds. A 0.1° backlash error at a single joint propagates through the kinematic chain. At the end of a 2-meter arm, it becomes 3 mm or more of TCP positioning error.
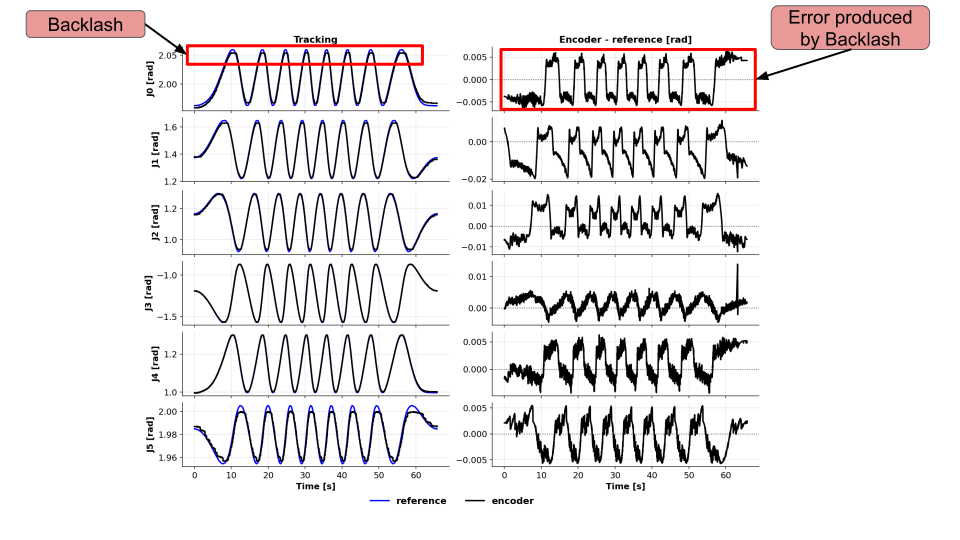
Encoder readings and tracking error during repeated reversals in the Reforge validation test.
Why milling exposes backlash more than other applications
Pick-and-place, welding, and palletizing applications often mask backlash because the robot moves in long, sweeping arcs with few reversals. The joints move predominantly in one direction for each segment of the path.
Milling is different. A robot following a contour — profiling a turbine blade root, machining an aircraft skin panel, or cutting a composite layup — reverses joint directions constantly. Every concave-to-convex transition, every pocket corner, every change in contour curvature forces one or more joints through a reversal. Each reversal triggers the backlash gap.
The result is visible on the part:
Witness marks at direction changes — small steps or ridges where the tool path shifts by the backlash error as joints reverse
Dimensional errors on contoured surfaces — the TCP tracks inside or outside the programmed path depending on the direction of approach
Surface finish degradation at corners and transitions — the tool dwells or skips as joints cross their backlash gaps, producing chatter marks or uneven material removal
Non-repeatable errors — because backlash depends on the direction of the last motion, the same programmed path can produce different results depending on how the robot arrived at each point
These errors are distinct from the robot’s static accuracy specification. A robot with ±0.05 mm repeatability can still produce 1-3 mm of path error during contour milling if backlash is uncompensated.
How shops deal with backlash today
The current approaches all involve working around the problem rather than solving it:
Approach | What it does | Trade-off |
|---|---|---|
Reduce feed rate | Slows the robot to minimize dynamic effects | Cycle time increases 2-5x; backlash gap still exists, just crossed more slowly |
Harmonic drives | Reduces the physical clearance between gear teeth | Higher cost per joint; Add compliance on the robot which limits payload |
CAM path compensation | Creates a tool path that avoids joint reversals instead of compensating for the backlash | Do not work for the for tool paths where backlash can not be avoided |
Finishing passes with manual correction | Operator measures and corrects after the robot pass | Defeats the purpose of automation; adds labor cost per part |
Buy a more expensive robot | Higher-end platforms with tighter mechanical tolerances | KUKA or Fanuc precision series costs 2-4x more; still has backlash, just less of it |
None of these approaches address the root cause: the controller doesn’t know the backlash exists and can’t compensate for it in real time.
How software-based backlash compensation works
Software-based compensation operates between the trajectory planner and the robot’s native servo controller. It tracks the direction of motion at each joint and applies a correction when a reversal is detected.
The process has two parts:
Calibration. The system drives each joint through a structured sequence of reversals and measures the actual deadband — the angular gap where the motor moves but the link does not. This is done once per robot and captures the specific backlash characteristics of that arm, including any asymmetry between joints and any configuration-dependent variation.
Real-time compensation. During operation, the software monitors the commanded trajectory for direction reversals at each joint. When a reversal is detected, it injects a correction equal to the identified deadband, so the motor crosses the backlash gap before the joint is expected to begin moving in the new direction. The joint starts its new motion already in contact — eliminating the lag.
This layer works alongside existing accuracy improvements. Kinematic calibration corrects the robot’s geometric model. Dynamic joint tracking compensates for compliance and lag. Backlash compensation handles the direction-reversal error that neither of those can address. Together, they reduce the total path error to a level that starts approaching what many milling operations require.
Measured results
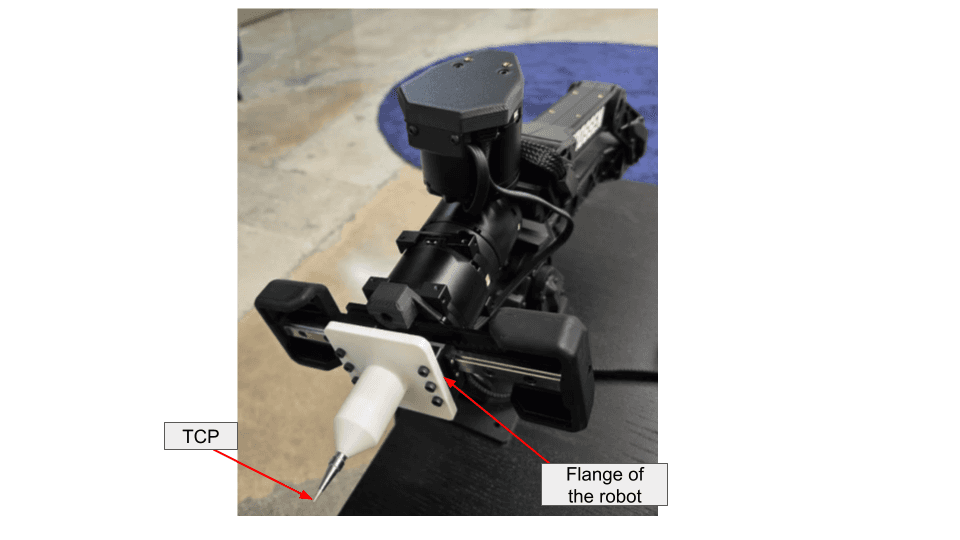
We validated backlash compensation on a trajectory specifically designed to force repeated joint reversals — the kind of multi-axis coordinated motion that robotic milling demands. The robot was commanded to track a circle with the flange center while holding the TCP fixed in Cartesian space, requiring all six joints to reverse direction continuously.
The validation setup: the metal tip marks the TCP, and the labeled flange follows the commanded circle.
Metric | Without compensation | With compensation | Improvement |
|---|---|---|---|
3-D TCP RMS tracking error | 4.131 mm | 0.878 mm | 4.70× |
All-joint RMS tracking error | 0.593° | 0.088° | 6.75× |
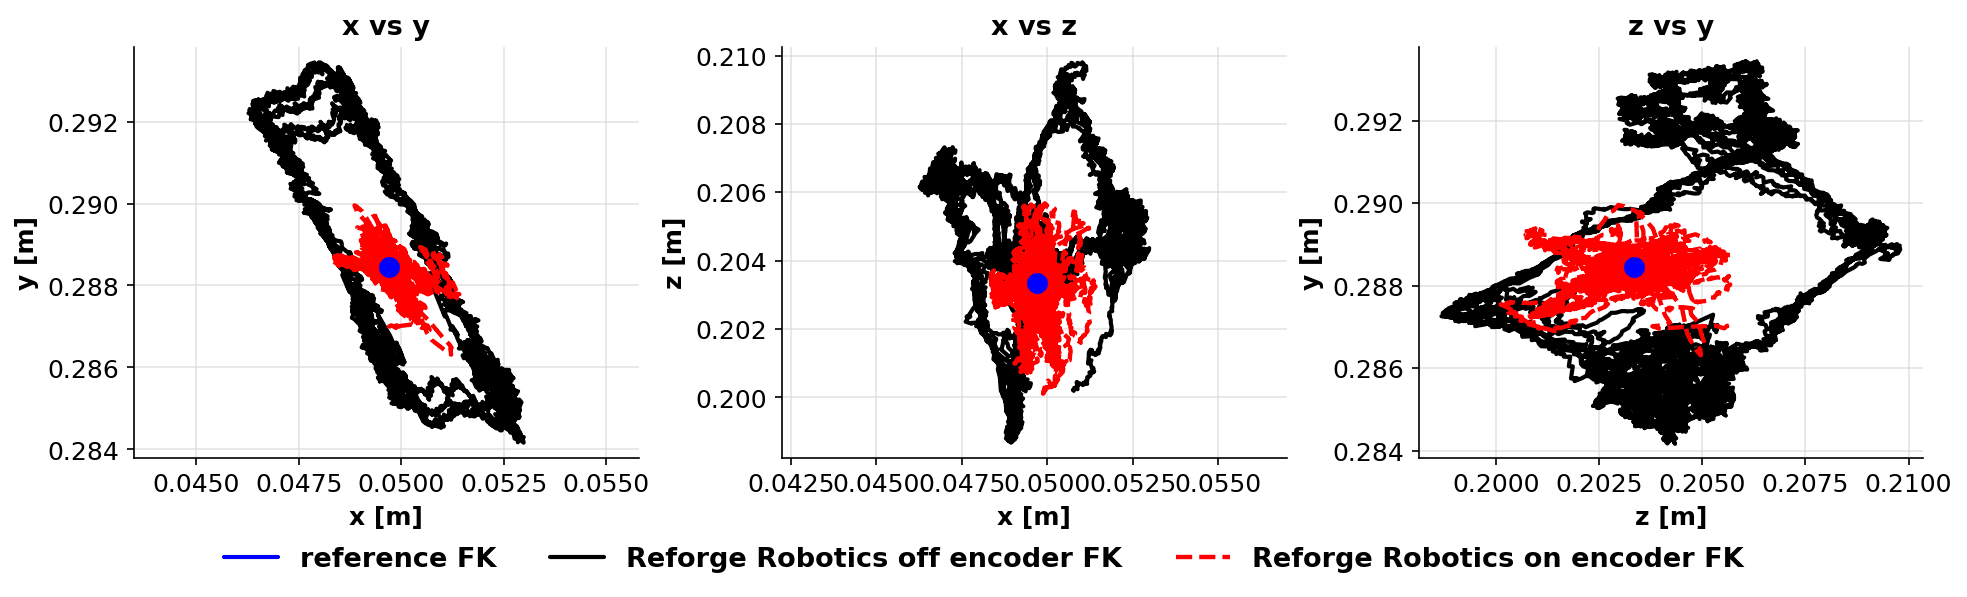
Estimated TCP position in the validation test. Black is software off, red is Joint Tracker plus Backlash Compensation on, and blue marks the fixed reference. These measurements evaluate the combined software effect, not backlash compensation alone.
The per-joint results show that the compensation is effective across all joints, not just the ones with the largest backlash:
Joint | Without compensation | With compensation | Improvement |
|---|---|---|---|
J0 | 0.330° | 0.076° | 4.37× |
J1 | 0.948° | 0.117° | 8.11× |
J2 | 0.927° | 0.108° | 8.59× |
J3 | 0.320° | 0.071° | 4.52× |
J4 | 0.319° | 0.051° | 6.26× |
J5 | 0.204° | 0.088° | 2.32× |
A 4.70× reduction in TCP tracking error during direction reversals changes what robotic milling can achieve. For a cell that was producing ±2 mm contour error, that drops to under ±0.5 mm — moving from rough machining territory into semi-finishing range without changing the robot, the spindle, or the CAM program.
What this means for your milling operation
Backlash compensation doesn’t turn a robot arm into a 5-axis CNC. The robot still has structural compliance, thermal drift, and dynamic limitations that a purpose-built machine tool doesn’t. But it removes one of the largest discrete error sources in robotic machining — and it does it through software, without mechanical modification.
For operations running KUKA, Fanuc, ABB, or other industrial platforms for milling, this means:
Tighter achievable tolerances on contoured surfaces and pocketed features — without slowing down
Reduced manual finishing after the robot pass — fewer witness marks, more consistent surface quality
Expanded part envelope — parts that previously required a CNC due to tolerance requirements may become viable on the robot cell
No hardware changes — deploys through the robot’s existing command interface as a software layer
The economics are straightforward. If backlash is costing you a finishing pass, a manual correction step, or a reject rate on contoured parts, software compensation addresses the root cause at a fraction of the cost of upgrading the robot.
FAQ
Can software really fix a mechanical problem like backlash?
Software doesn’t eliminate the physical gear clearance. It compensates for it by anticipating direction reversals and injecting corrective motion before the joint crosses the deadband. The gear teeth still have clearance — but the joint is already positioned to the correct side of the gap when the new motion begins.
Does backlash compensation work at high feed rates?
Yes. The compensation operates at the servo loop level, so it applies regardless of feed rate. In fact, higher speeds tend to benefit more because the dynamic effects of crossing the backlash gap — including the momentary loss of contact and the impact on re-engagement — are more pronounced at speed.
Which industrial robots have the worst backlash?
Backlash is present in every gear-driven robot. Robots with cycloidal or harmonic drive reducers (common in cobots and smaller industrial arms) tend to have less backlash than those with planetary gearboxes. However, even low-backlash drives accumulate wear over time. The actual backlash of a specific robot depends on its age, usage history, and maintenance. That’s why per-robot calibration matters more than platform-level specifications.
How does this compare to buying a higher-precision robot?
A precision-grade industrial arm (e.g., KUKA KR Fortec Precision or Fanuc M-20iD/25 series) reduces backlash through tighter mechanical tolerances. The trade-off is cost — typically 2-4× the base model — and the backlash still increases with wear. Software compensation can be deployed on any arm and recalibrated as conditions change, at a fraction of the hardware upgrade cost.
Reforge Robotics builds control software that makes industrial robots more accurate. Backlash compensation is part of the Covalent Joint Tracker product. Book a demo to see it on your platform.
Nosa Edoimioya
Founder & CEO
Share post
Written by
Nosa Edoimioya, Founder & CEO